
4.8kg

NERO 7-DoF
Humanoid Robotic Arm
Core Performance Metrics
3kg
Payload
580mm
Reach
±0.1mm
Repeatability
7-DoF Robotic Arm for Human-Like Motion
NERO’s redundant 7-axis architecture provides more flexible posture control and human-like movement for humanoid robotics, embodied AI, and complex manipulation.
4.8 kg Lightweight Design with a 3 kg Payload
Combining a lightweight 4.8 kg design with a 3 kg payload, NERO is easy to carry and deploy across research environments while delivering professional performance for humanoid research and real-world robotic prototyping.
Modular Platform & Open Architecture for System Extension
Support for tabletop, side-mounted, and inverted installation, together with Python SDK, ROS / ROS2, Gazebo, CAN, HTTP, and TCP support, NERO enables rapid algorithm development, simulation, trajectory planning, and custom system integration.

Who is Using NERO
Supporting the development of humanoid robotics, embodied AI, physical interaction data collection, and real-world robotic systems.
Universities & Robotics Labs
For robotics research, manipulation planning, bimanual teleoperation, bimanual coordination, and humanoid robot development.
Robotics Solution Providers
For building deployable robotic systems by integrating NERO with mobile platforms, end-effectors, and custom control software.
Industrial Automation Teams
For developing real-world robotic applications in handling, assembly, inspection, testing, and customized automation.
Robotics Startups
For rapid prototyping, Python/ROS-based development, simulation, algorithm validation, and next-generation humanoid robot applications.
NERO User Cases
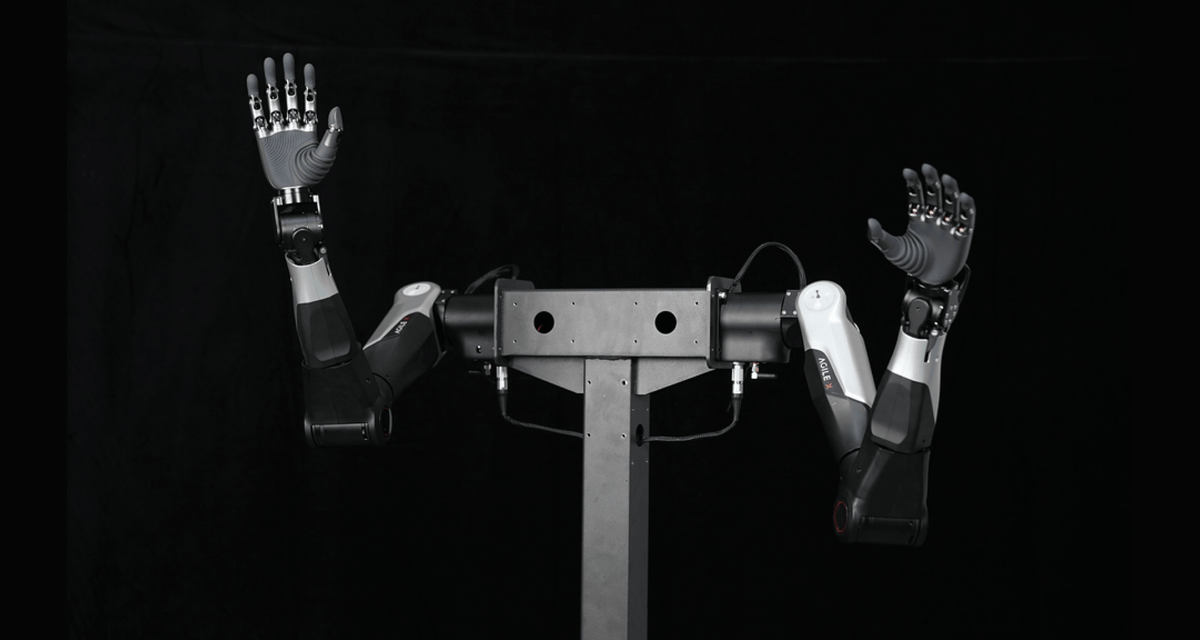
Humanoid System Integration
Integrate NERO into humanoid and upper-body robotic systems for dexterous arm motion and manipulation.
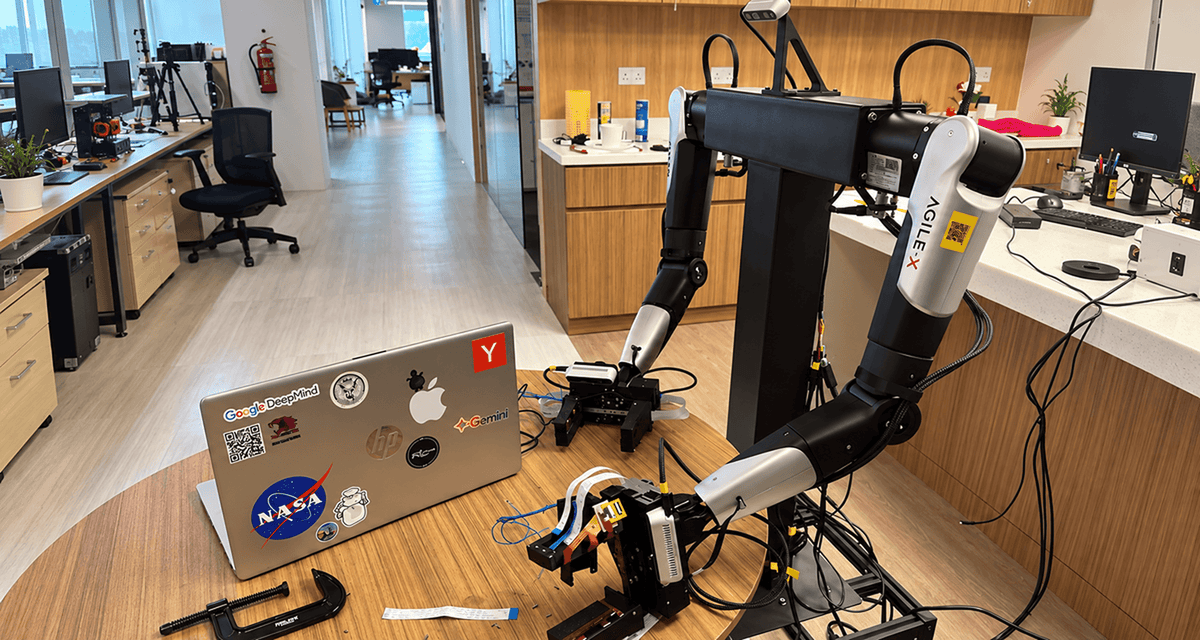
Robot Manipulation & Coordination Research
Explore motion control, bimanual coordination, teleoperation, and advanced manipulation algorithms.
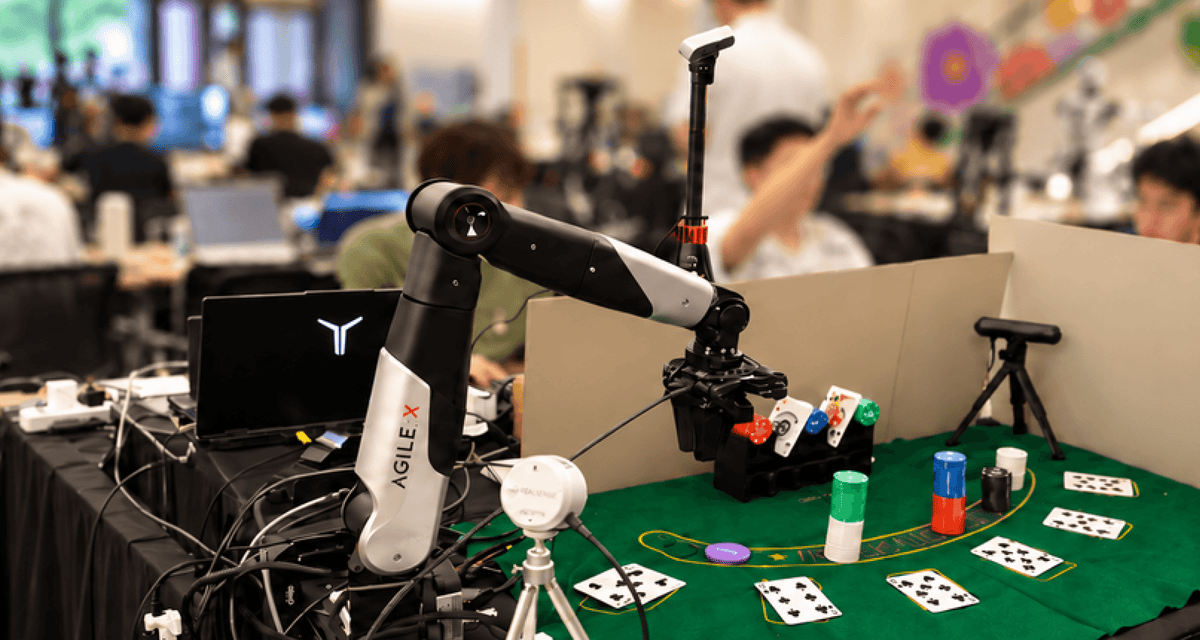
Creative Robotics Development
Build interactive and creative robotic applications for performance, demonstration, and experimentation.
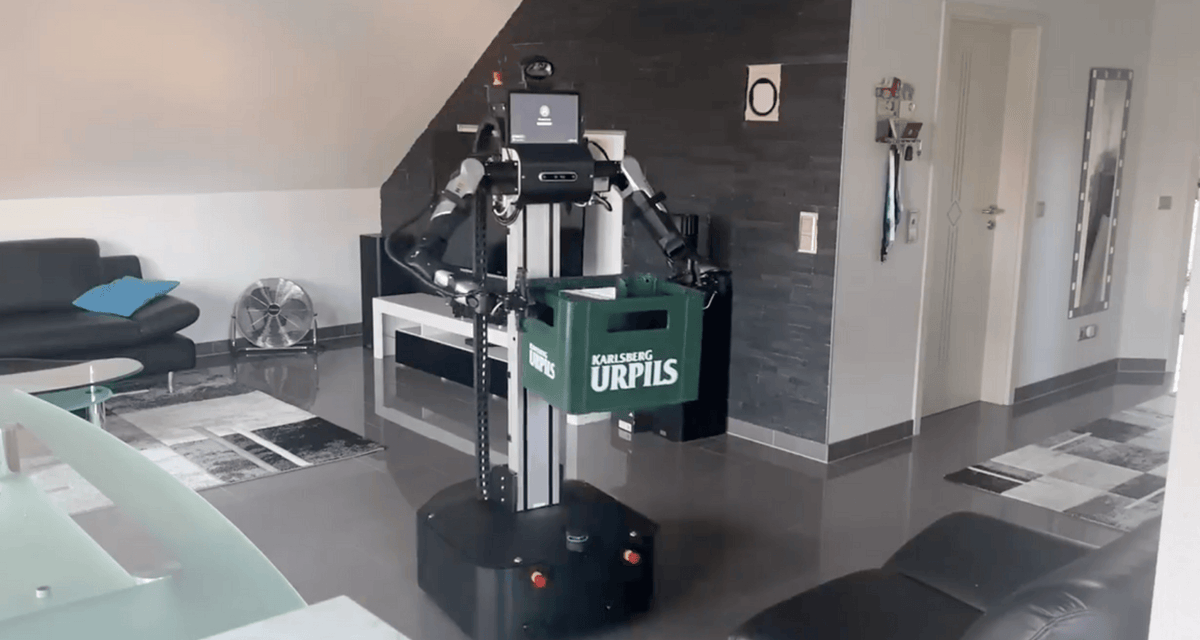
Real-World Applications
Deploy flexible robotic manipulation for real-world tasks across diverse environments and workflows.
Complete Ecosystem
Seamless integration with industry-standard hardware and software.
Components & Accessories
Equip NERO with perception and end-effector hardware for robotic manipulation, system integration, and physical AI research.

Dexterous Hand

Depth Camera

Gripper & End Effector

Desktop Fixture

Emergency Stop

Dual-Arm Stand
Software & Algorithms
Build and validate desktop robotic arm applications with integrated control tools, open SDKs, and simulation support.
ROS 1 / ROS 2
Python SDK
URDF & MoveIt 2
Isaac Sim / Isaac Lab
Related Solutions
Extend NERO into complete robotic systems for bimanual system, physical AI research, and real-world applications.

Bimanual Teleoperation
Powered by two NERO 7-DoF robotic arms, OPEN NERO is a dual-arm platform for bimanual manipulation and embodied AI research.
Learn More
Teleoperation Data Collection
Universal Master Arm is a lightweight leader arm that enables real-time robot following through 6D pose mapping and IK-based control, supporting both single-arm and dual-arm teleoperation with NERO and PiPER.
Learn MoreFAQ
NERO is a lightweight 7-DoF humanoid robot arm that combines highly dexterous motion, 3kg payload capacity, and open development interfaces for humanoid robotics, embodied AI research, and real-world robotic applications.
Yes. NERO is designed for robotics development workflows and supports ROS-based development as well as SDK/API integration. Its user manual explicitly provides a Python API for secondary development, while the robot also supports CAN, HTTP, and TCP communication.
Yes. NERO can be integrated into automation workflows such as robotic assembly, handling, laboratory automation, and other manipulation tasks. It supports API-based control, offline trajectories, drag teaching, and host-computer control, making it easier to connect with higher-level automation systems.
Yes. NERO supports leader-follower linkage control. The follower arm can track the motion of the leader arm in real time, making NERO suitable for teleoperation, robot data collection, and embodied AI data workflows.
Yes. A common workflow is to run robotics foundation models such as OpenVLA, π0, NVIDIA GR00T N1, as well as world models such as NVIDIA Cosmos, on a workstation or edge computer, then send motion commands to NERO through ROS, SDK, or other control interfaces.
Yes. NERO is designed for a range of robotics applications, including humanoid robots and automated handling systems. It supports tabletop, side, and inverted mounting, making it easier to integrate into fixed workstations, mobile manipulators, or other robotic platforms.
NERO has already been adapted to multiple dexterous-hand platforms, including BrainCo Revo2, Linker Hand LH06, OYMotion ROH-Lite S001, and BrainCo Revo2 tactile version.
Dexterous hands can be integrated with NERO through its end-effector flange, with an appropriate adapter or flange plate depending on the hand model. On the software side, integration can be achieved through network protocols, Web control, ROS packages, or SDKs, depending on the hand. End-effector parameters can then be configured in NERO for accurate motion control and torque compensation.
SPECIFICATIONS
Technical Specifications
DoF
7
Payload
3kg
Weight
4.8kg
Repeatability
±0.1mm
Reach
580mm
Voltage
DC 24V
Interface
CAN
Temperature
-20~50℃
Humidity
25~85%
Mounting Dimensions
70*70mm
J7 Joint Range
±97°
J7 Joint Speed
225°/s
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.