
1.67m/s

SCOUT 2.0
Heavy-Duty Off-Road UGV
Core Performance Metrics
50kg
Payload
2.5Hours
Runtime (Full Load)
30°
Climb
Off-Road Mobility & Independent Suspension
Front and rear double-wishbone independent suspension, 115 mm ground clearance, 30° climbing capability, and 200 mm gap-crossing performance help SCOUT 2.0 move through challenging terrain.
Open Expansion & Complete System Integration
With 24V 10A external power and reserved interfaces for LiDAR, RTK/INS, robotic arms, automatic charging docks, and other modules, SCOUT 2.0 can be adapted into various complete robotic systems.

Who Is SCOUT 2.0 For?
Built for outdoor robotics developers and solution providers deploying autonomous systems across open, uneven, and changing environments.
Security & Patrol Solution Providers
For teams building autonomous patrol robots for industrial parks, campuses, construction sites, utilities, and large outdoor properties.
Agricultural Robotics Companies
For developers creating robots for crop monitoring, field inspection, precision agriculture, and autonomous operations in farms and greenhouses.
Infrastructure & Utility Operators
For organizations inspecting power facilities, pipelines, transportation assets, water sites, and other distributed outdoor infrastructure.
Field Robotics & Research Teams
For research institutions and engineering teams validating autonomous navigation, perception, multi-sensor fusion, and robot mobility beyond controlled indoor environments.
SCOUT 2.0 User Cases
Explore research, prototyping, algorithm validation, and application development with an open mobile robot platform.
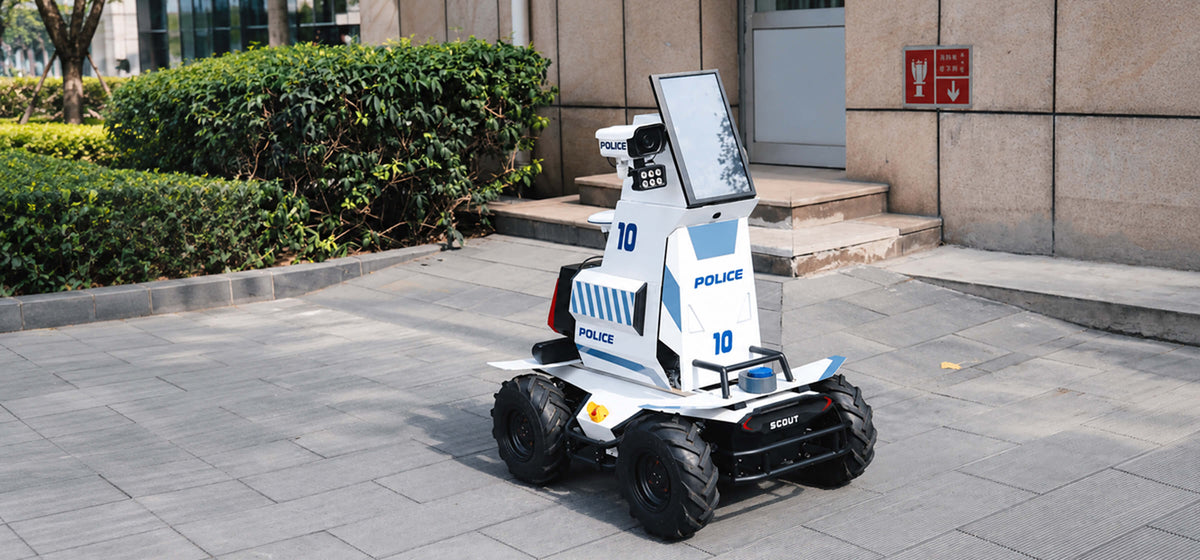
Unmanned Security & Patrol
Integrate cameras, LiDAR, and communication equipment to perform scheduled patrols, monitor designated routes, and support more continuous site awareness.

Intelligent Agriculture
Mount vision, environmental, and navigation sensors to develop field-monitoring, crop-inspection, and precision-agriculture robot applications.
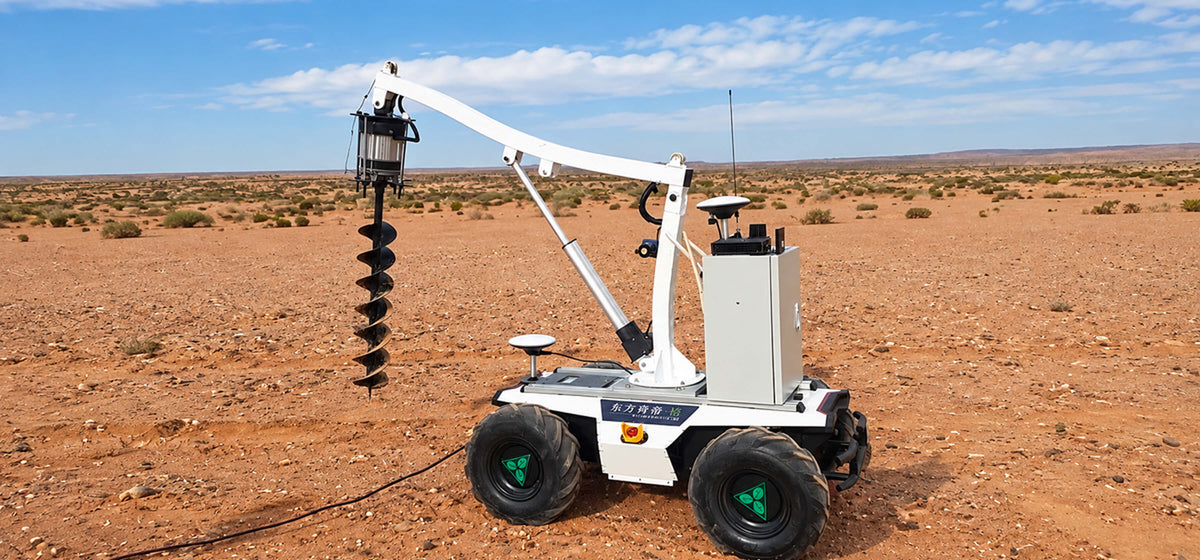
Field Exploration Robot
Build a sensor-equipped mobile platform for environmental monitoring, remote-site exploration, terrain assessment, and outdoor robotics research.
Complete Ecosystem
Seamless integration with industry-standard hardware and software
Components & Accessories
Easily expand SCOUT 2.0 with compatible sensors, onboard computing, robotic arms, and application-specific payloads.

Robotic Arm

Computing Unit

LiDAR

Custom Payload
Software & Algorithms
Access open development resources for ROS, simulation, SLAM, navigation, perception, and robot control.
CAN Bus & SDK Control
ROS 1 / ROS 2 Integration
SLAM & Navigation Stack
Gazebo Simulation
FAQ
SCOUT 2.0 is an open outdoor mobile robot platform for applications such as autonomous patrol, agricultural monitoring, infrastructure inspection, field exploration, and outdoor robotics research.
SCOUT 2.0 is designed for outdoor routes and uneven ground. Actual performance depends on terrain conditions, slope, payload, tires, sensor configuration, and the complete robot system.
Yes. It can be configured with LiDAR, cameras, thermal sensors, environmental sensors, and onboard computing to build autonomous patrol, inspection, and remote-monitoring robots.
Yes. Developers can integrate navigation sensors and software for mapping, localization, route planning, and obstacle avoidance. A complete deployment should also include application-specific safety design and site validation.
A typical configuration includes the mobile platform, onboard computer, navigation sensors, communication hardware, and task-specific payloads such as cameras or environmental sensors. The final setup depends on the crop, terrain, operating route, and data-collection requirements.
SPECIFICATIONS
Technical Specifications
Motion Mode
Differential
Weight
67kg
dimensions (mm)
930*699*337
IP Rating (Customizable)
IP22
Ground Clearance
115mm
Temperature
-10~40℃
Runtime (Full Load)
2.5hour
Climb
30°
Obstacle Clearance
110mm
Max Speed
1.67m/s
Max Range
15km
Payload
50kg
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.