
4

LIMO PRO
ROS 2 Mobile Robot Platform
Core Performance Metrics
4.8kg
Payload
4hours
Runtime
45°
Max Climb (Track Mode)
Four Motion Modes, One Customizable Platform
Supports interchangeable mobility configurations, including Ackermann steering, differential drive, Mecanum wheels, and tracked mobility.
Integrated AI Computing and Perception System
Integrated NVIDIA Jetson Orin Nano, an EAI T-mini Pro LiDAR, Orbbec DaBai depth camera, and HI226 IMU provide an onboard foundation for real-time mapping, perception, object recognition, and autonomous robot development.
Open ROS Environment, From SLAM to Navigation
LIMO PRO provides ROS resources, C++ and Python interfaces, source code, simulation models, and hands-on tutorials. Developers can develop localization, obstacle avoidance, route planning, and autonomous inspection workflows with ROS navigation tools.
Who is Using LIMO PRO
Built for robotics education, autonomous-driving research, AI algorithm development, and rapid mobile robot prototyping.
Universities & Robotics Labs
For ROS education, mobile robot research, kinematics experiments, and autonomous-navigation development.
Robotics and AI Educators
For teaching Python, C++, SLAM, perception, path planning, and robot-control fundamentals through hands-on projects.
Student Competition Teams
For robotics competitions, capstone projects, and rapid prototyping that require adaptable mobility and onboard perception.
Developers & Product Prototyping Teams
For validating mobile robot algorithms, sensor configurations, and application concepts before custom hardware development.
LIMO PRO User Cases
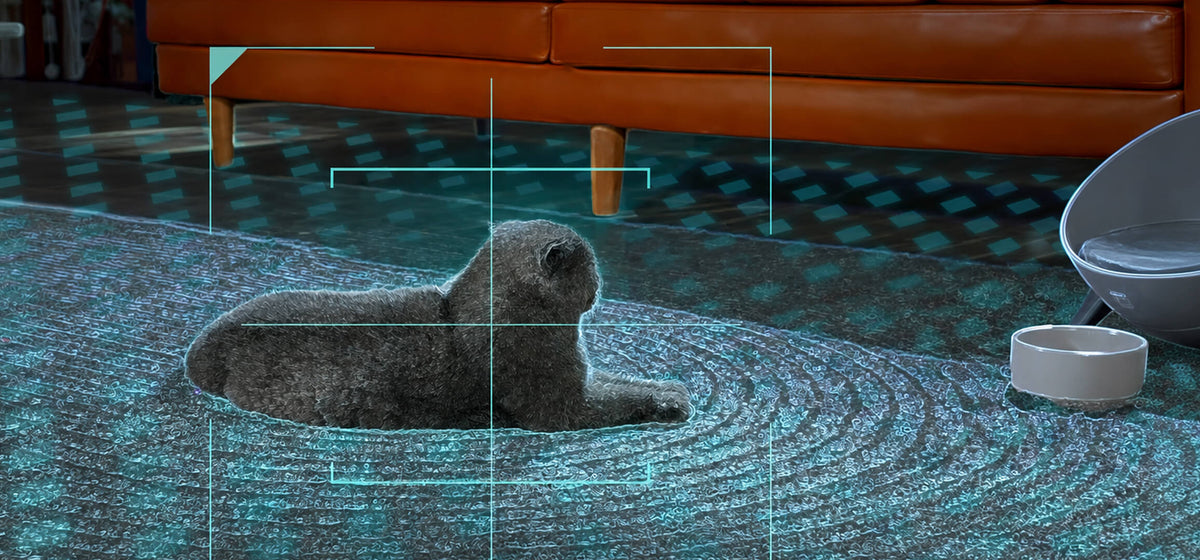
Object Detection & Recognition
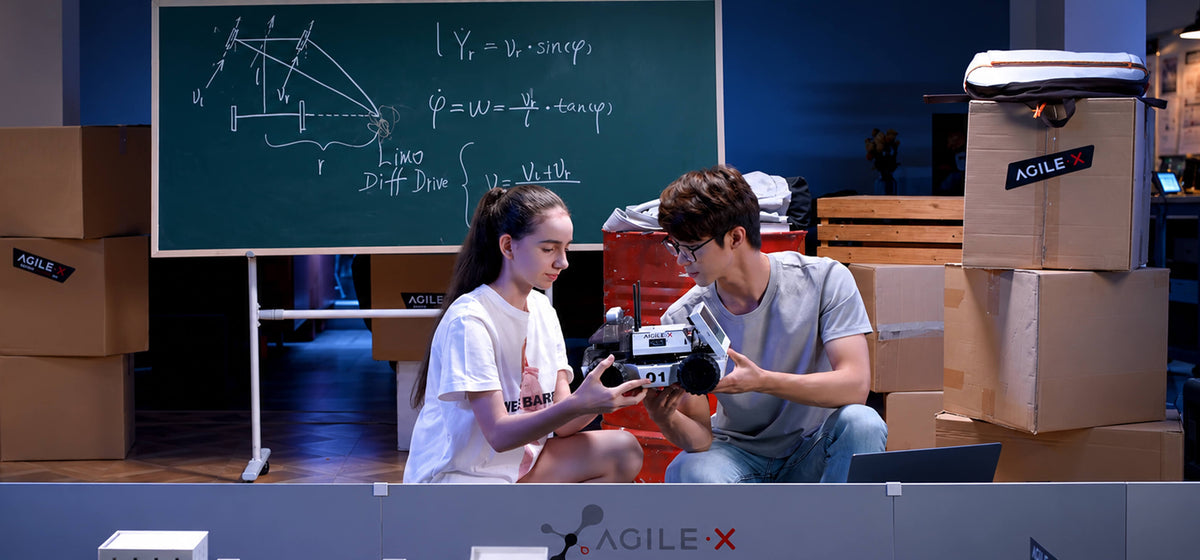
Robotics Education
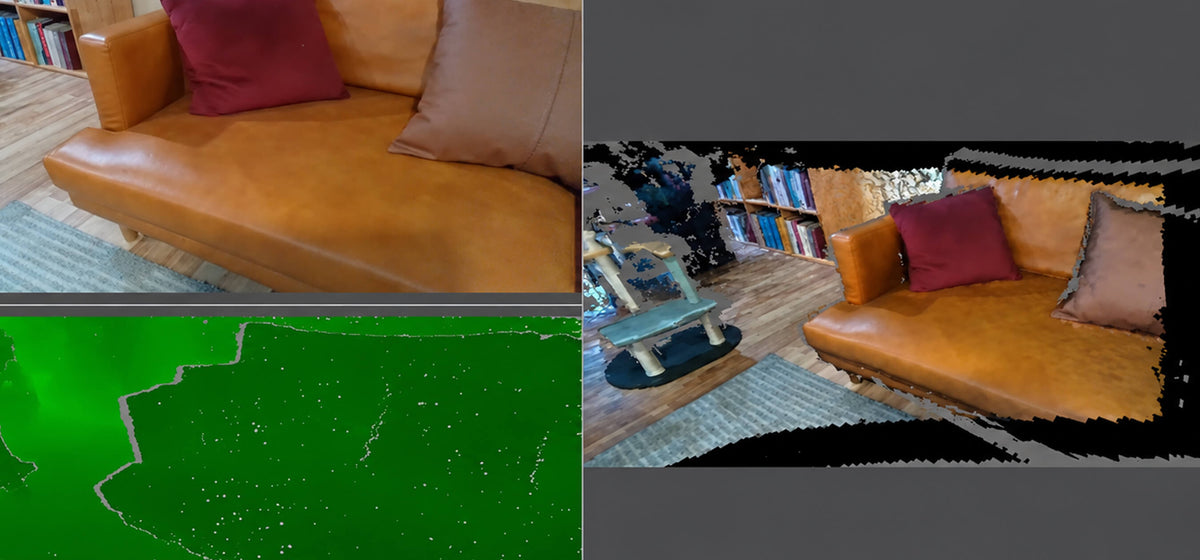
Visual SLAM Mapping
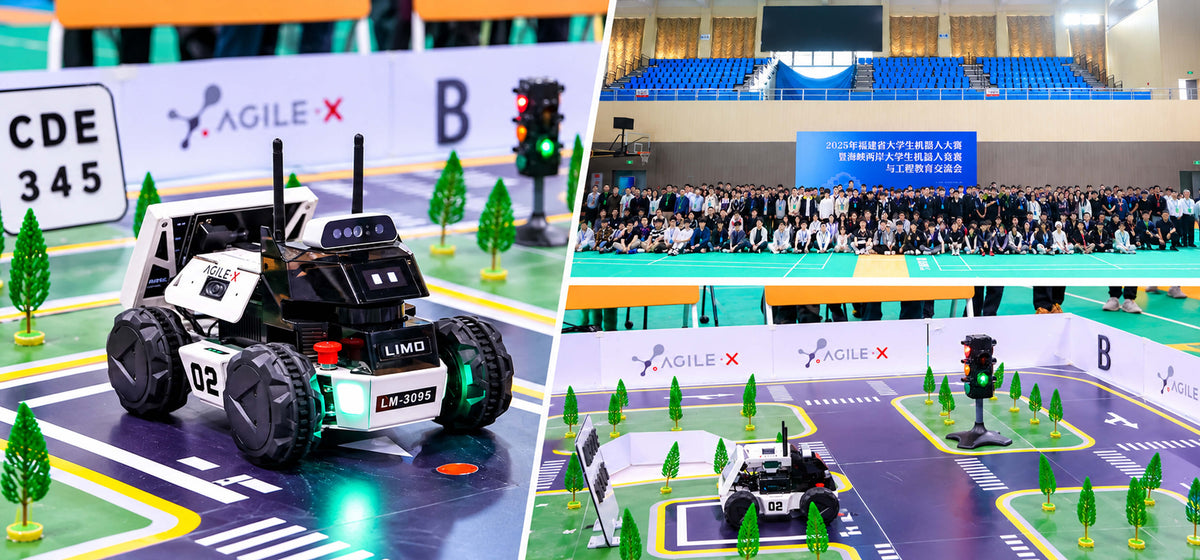
Robotics Conference & Competition
Complete Ecosystem
Seamless integration with industry-standard hardware and software.
Components & Accessories
Configure LIMO PRO with multiple mobility modes and scenario-based training arenas.

Tracks

Mecanum Wheels

Onboard Computing

Sand Table
Software & Algorithms
Develop with ROS, SDKs, simulation tools, and resources for SLAM, navigation, perception, and robot control.
ROS 1 / ROS 2
Phython & C++ SDK
Gmapping / Cartographer / RTAB-Map
DWA / TEB Navigation
FAQ
LIMO PRO is a four-mode ROS robot development platform for education, research, and mobile robotics prototyping. It supports Ackermann, differential, Mecanum-wheel, and tracked motion configurations.
LIMO PRO is an open, reconfigurable platform focused on mobile-robot learning and development. Its standard configuration does not include a robotic arm. LIMO COBOT is a more integrated ROS 2 mobile manipulation platform that combines the mobile base, 6-DoF arm, perception hardware, and ready-to-use grasping workflows.
Users can develop SLAM, autonomous navigation, obstacle avoidance, visual recognition, line following, voice interaction, AI inference, and optional mobile-manipulation applications.
LIMO PRO supports commonly used ROS navigation and mapping algorithms, including Gmapping, Cartographer, RTAB-Map, AMCL localization, DWA local planning, and TEB local planning. With its onboard LiDAR, depth camera, IMU, and Jetson computing, developers can build and evaluate laser SLAM, visual SLAM, autonomous navigation, obstacle avoidance, and multi-point patrol applications.
Use Ackermann mode for car-like steering, differential drive for standard indoor mobile robotics, Mecanum mode for omnidirectional movement, and tracked mode for improved terrain adaptability.
Technical Specifications
dimensions (mm)
322*220*251
weight
4.8kg
Max climb (Track Mode)
45°
runtime
4hours
LiDAR
2DLiDAR
Depth Camera
Orbbec DaBai
Onboard PC
Orin Nano
Obstacle Clearance
24mm
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.