
4

LIMO COBOT
Mobile Manipulation Education Platform
Core Performance Metrics
5.6kg
Payload
2.5hours
Runtime
250g
Payload (Robotic Arm)
Four Mobility Modes, Integrated Manipulation
A reconfigurable mobile platform integrates a lightweight 6-DoF robotic arm, combining four motion modes with hands-on mobile manipulation development. Students can explore the full robotics loop: move, perceive, approach, grasp, place, and repeat.
Advanced Perception for Navigation and Grasping
Powered by NVIDIA Jetson Orin Nano, EAI T-mini Pro LiDAR, Orbbec Astra+ depth camera, and high-precision IMU, LIMO COBOT supports SLAM, dynamic obstacle avoidance, object detection, and pose estimation.
ROS 2 Ready, Teaching Friendly
Complete ROS 2 courses and open-source code cover Python programming, sensor fusion, path planning, and visual grasping. An optional sand table is also available for experiments and demonstrations.
Who is Using LIMO COBOT
Built for robotics education, mobile manipulation research, AI algorithm development, and rapid robot prototyping.
Universities & Technical Colleges
For ROS 2, mobile manipulation, embodied AI, and intelligent robotics courses.
Robotics Competition & Training Programs
For preparing teams to build integrated navigation, perception, and grasping demonstrations.
Mobile Manipulation Research Team
For validating perception-to-action pipelines, vision-guided grasping, and coordinated base-arm control at an accessible scale.
STEM Learning Projects
For capstone projects that combine autonomous navigation, AI vision, and robotic manipulation on one robot.
LIMO COBOT User Cases
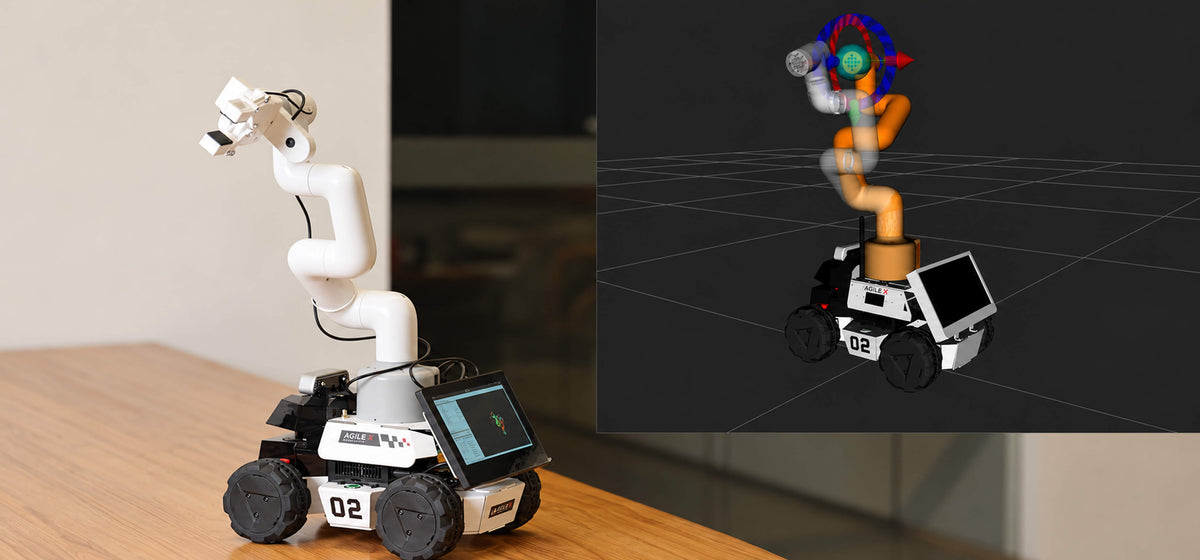
University Robotics Education & Sim-to-real Research
Support hands-on robotics education and sim-to-real research in navigation, perception, mobile manipulation, and embodied AI.
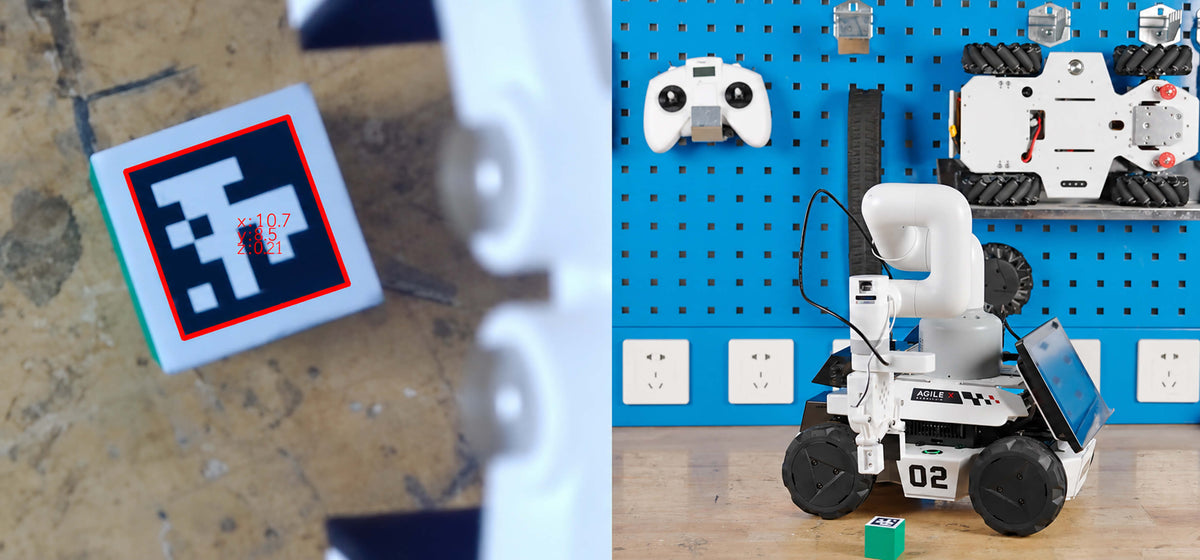
Robotics Competitions & Prototyping Validation
Build compelling autonomous demonstrations such as item delivery, visual sorting, object retrieval, and interactive service-robot tasks.
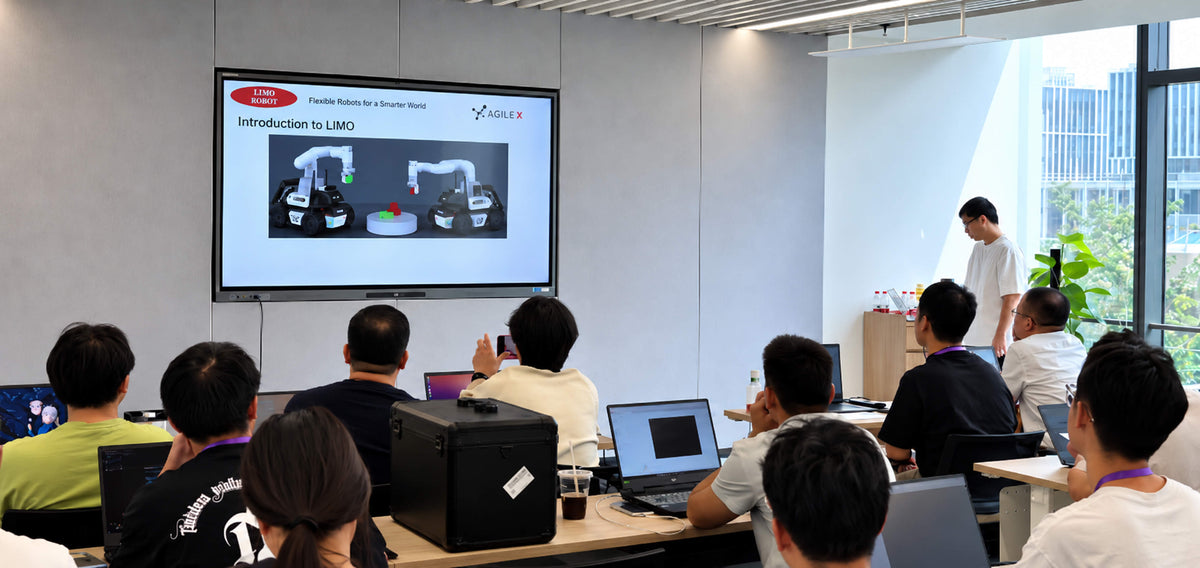
ROS 2 Mobile Manipulation Courses
Students can get hands-on learning on the integration of robot control, SLAM mapping, autonomous navigation, depth perception, arm kinematics, and grasp planning.
Complete Ecosystem
Seamless integration with industry-standard hardware and software.
Components & Accessories
Configure LIMO COBOT with multiple mobility modes and scenario-based training arenas.

Tracks

Mecanum Wheels

Onboard Computing

Sand Table
Software & Algorithms
Develop with ROS, SDKs, simulation tools, and resources for SLAM, navigation, perception, and robot control.
ROS 1 / ROS 2
Phython & C++ SDK
Gmapping / Cartographer / RTAB-Map
DWA / TEB Navigation
FAQ
LIMO COBOT is an integrated ROS 2 mobile manipulation education robot. It combines a four-mode mobile base, a 6-DoF robotic arm, onboard AI computing, and multi-sensor perception for navigation and vision-guided grasping.
LIMO PRO is primarily an open four-mode ROS development platform for mobile-robot education and algorithm development. LIMO COBOT is configured as a ready-to-use mobile manipulation platform, with an integrated arm and perception stack for complete navigation-and-grasping projects. LIMO COBOT is based on the LIMO PRO mobile platform.
Yes. Its LiDAR, depth camera, IMU, and onboard computing support mapping, localization, obstacle avoidance, and autonomous-navigation development through ROS 2.
LIMO COBOT integrates NVIDIA Jetson Orin Nano computing, an EAI T-mini Pro LiDAR, an Orbbec Astra+ depth camera, a high-precision IMU, and a lightweight 6-DoF robotic arm. Together, these components support SLAM, autonomous navigation, obstacle avoidance, object detection, pose estimation, and vision-guided grasping development.
LIMO COBOT is supported by ROS 2 course materials, open-source code, simulation models, experiment manuals, and project-based learning resources. Topics include Python programming, mobile robot control, sensor fusion, SLAM, path planning, computer vision, and mobile manipulation. An optional robotics sand table is also available for structured navigation, obstacle-avoidance, and autonomous-task experiments.
Yes. Multi-sensor fusion enables intelligent object recognization. The integrated 6-DoF arm supports close-range manipulation tasks. Combined with depth perception and vision algorithms, it can be used to develop object detection, pose estimation, pick-and-place, and vision-guided grasping demonstrations.
Technical Specifications
dimensions (mm)
322*220*251
weight
5.6kg
Max climb (Track Mode)
45°
runtime
2.5hours
Obstacle Clearance
24mm
Precision (Robotic Arm)
±0.5mm
Payload (Robotic Arm)
250g
working radius
280mm
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you within 24 hours.