
0.6kg

Universal Master Arm
Core Performance Metrics
505mm
Workspace
±180°
Handle Range
0.1ms
Latency

6-DoF Teleoperation, Precise Control
Translate human motion into continuous robot movement through 6D pose mapping and inverse kinematics with high precision and low latency.

Lightweight Design, Simplified Setup
Weighing only 0.6kg, the Universal Master Arm features an integrated CAN module and connects directly to a host computer via USB, reducing external hardware and enabling rapid deployment.

Customizable Workspace Limits
Users can customize motion boundaries to keep teleoperation within a safe zone. If a target pose exceeds the configured limits or cannot be reached, the system automatically halts the robotic arm, preventing unintended motion for safer operation.

One Teleoperation Platform, Universal Compatibility
Compatible with robotic arms from AgileX Robotics, including 7-DoF NERO and 6-DoF PiPER series. Third-party platforms can also be integrated by adapting the robot model, IK solver, and control interface.
Who is Using Universal Master Arm
Supporting teleoperation, robot learning, manipulation research, and real-world data collection across robotics development and embodied AI applications.
Universities & Robotics Labs
For research in teleoperation, robot manipulation, motion control, imitation learning, and human-robot interaction.
Foundation Model Providers
To collect real-world manipulation demonstrations for training and evaluating VLA and embodied foundation models across different robot embodiments.
Robot Data Providers
Build scalable teleoperation pipelines for producing high-quality manipulation datasets across multiple tasks and robot platforms.
Robotics Companies
For rapid development of leader-follower control, robotic arm teleoperation, manipulation workflows, and cross-robot integration.
User Cases
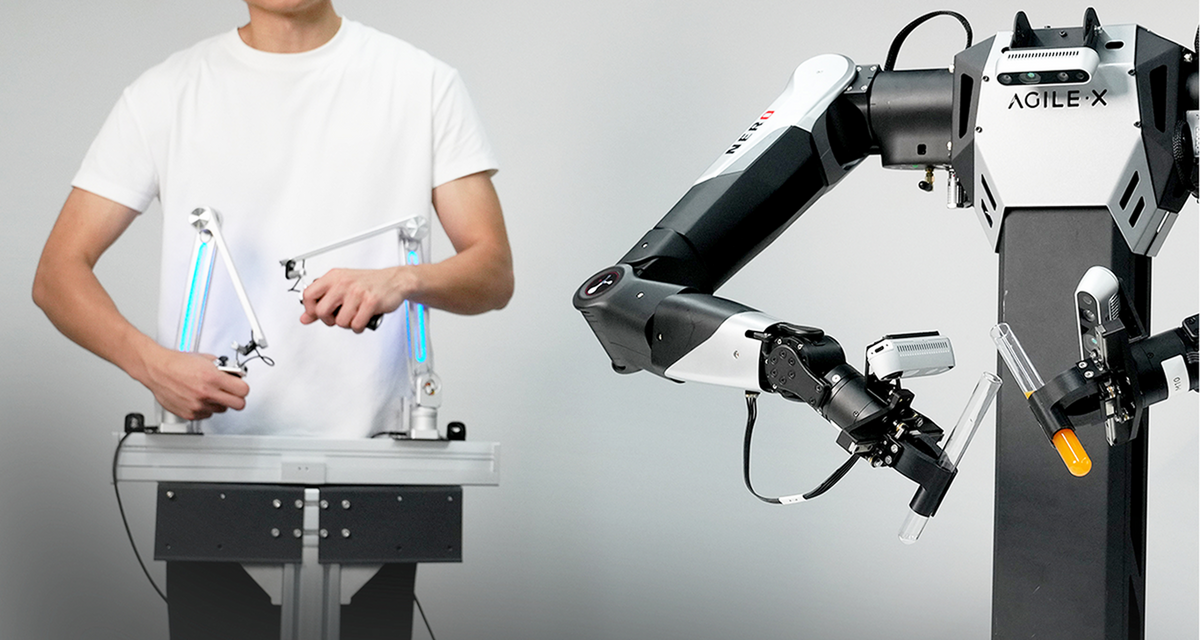
Bimanual Teleoperation & Data Collection
Synchronized dual-arm teleoperation for complex manipulation and real-world data collection.
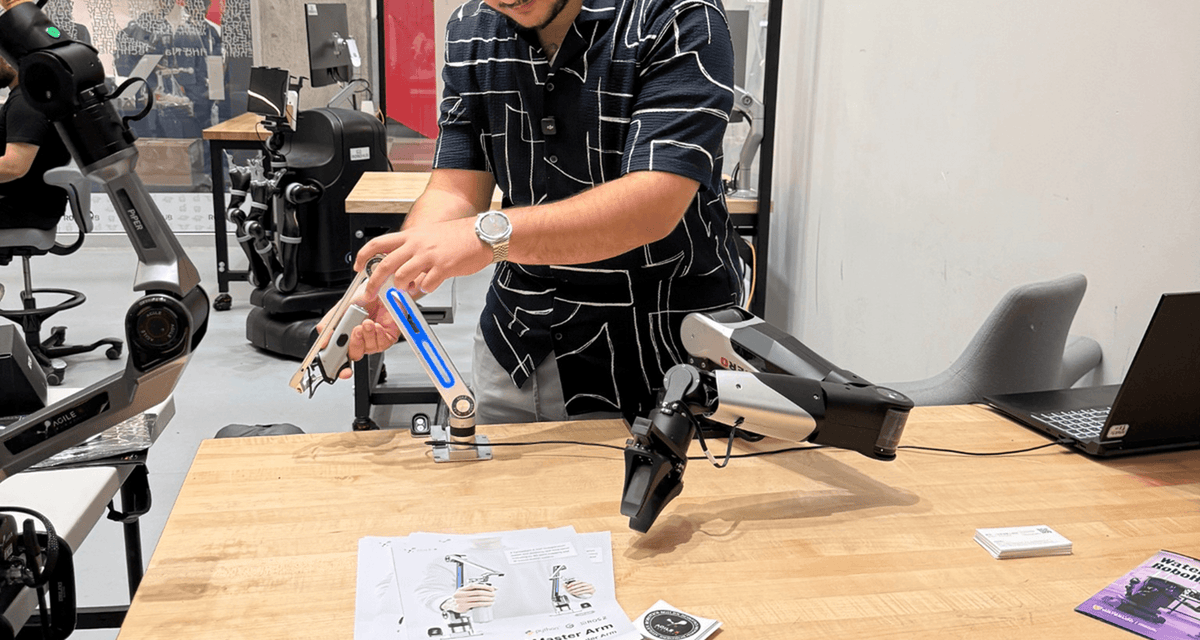
Interactive Demonstration & Robotics Education
Intuitive hands-on control for robotics teaching, training, and interactive demonstrations.
Related Solutions
Pair the Universal Master Arm with robotic arms that have different configurations for scalable data collection and lower equipment costs.

Bimanual Teleoperation
Pair the Universal Master Arm with the 7-DoF dual-arm platform OPEN NERO for dual-arm manipulation, teleoperation, and embodied AI data collection.
Learn More
Compact Single-Arm Teleoperation
Pair the Universal Master Arm with a 6-DoF robotic arm PiPER for flexible teleoperation and efficient robot data collection.
Learn MoreFAQ
Universal Master Arm is a lightweight 6-DoF teleoperation leader arm designed for robotic arm control and human demonstration. It enables real-time teleoperation through 6D pose mapping and IK-based motion, ideal for robot learning, and embodied AI research.
The Universal Master Arm captures 6D pose input and maps the operator’s motion to the follower robot through pose mapping and inverse kinematics (IK), allowing intuitive leader–follower teleoperation.
Yes. The Universal Master Arm supports ROS 2-based development as well as Python and C++, making it suitable for custom robot control, teleoperation, and robotics research workflows.
Universal Master Arm supports both 6-DoF and 7-DoF robotic arms, as well as single-arm and dual-arm setup. It enables teleoperation across different robotic arm platforms and control architectures by integrating the corresponding robot model, IK solver, and control interface, providing an efficient and cost-effective solution for robot data collection.
It is designed for robotics developers, embodied AI and foundation model teams, robot data providers, research laboratories, and system integrators working on teleoperation, manipulation, and robot learning.
Universal Master Arm is a lightweight 6-DoF teleoperation leader arm designed for robotic arm control and human demonstration. It enables real-time teleoperation through 6D pose mapping and IK-based motion, ideal for robot learning, and embodied AI research.
Technical Specifications
DoF
6
Weight
0.6kg
latency
0.1ms
Workspace
505mm(Hemi.)
Reach
415mm
Voltage
DC 5V
HANDLE RANGE
±180°
Temperature
0~45℃
Encoder Res.
16bit
Interface
Type-C
Angular Accuracy
±1°
Position Accuracy
±5mm
Tell Us Your Needs
Connect with our robotics experts to discuss your automation needs and discover the perfect mobile platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you within 24 hours.