
4.5kg

PiPER-X 6-DoF
Robotic Arm
Core Performance Metrics
1.5kg
Payload
669mm
Reach
±0.1mm
Repeatability
Human-Like Wrist Dexterity
Integrated with an agile sphere wrist, with ±90° J4/J5 and ±165° J6 rotation, PiPER-X provides flexible end-effector orientation for grasping, manipulation, and imitation learning.
Research-Ready With Open Software Stack
Supports drag teaching, trajectory replay, and PC control. Compatible with Python, ROS 1/ROS 2, URDF, Gazebo, and Isaac Sim, taking robotics development from motion validation to sim-to-real development.
Reliable Precision for Reproducible Research
With ±0.1 mm repeatability, drag-to-teach, and trajectory replay, PiPER-X helps research teams validate algorithms with consistent and repeatable movements.
Who is Using PiPER-X
Supporting the practical needs of embodied AI research, robotics development, manipulation experiments, and compact automation in constrained workspaces.
Universities & Robotics Labs
For compact pick-and-place, robot manipulation, motion planning, imitation learning, and repeatable laboratory experiments.
Robotics R&D Companies
For rapid prototyping of robotic applications, custom control algorithms, sensor integration, and ROS/ROS2-based system development.
Educators & Advanced Makers
For hands-on robotics education, Python development, desktop robot experiments, and fast proof-of-concept development.
Industrial Solution Providers
For developing deployable collaborative robot arm systems and delivering customized automation solutions.
PiPER-X User Cases
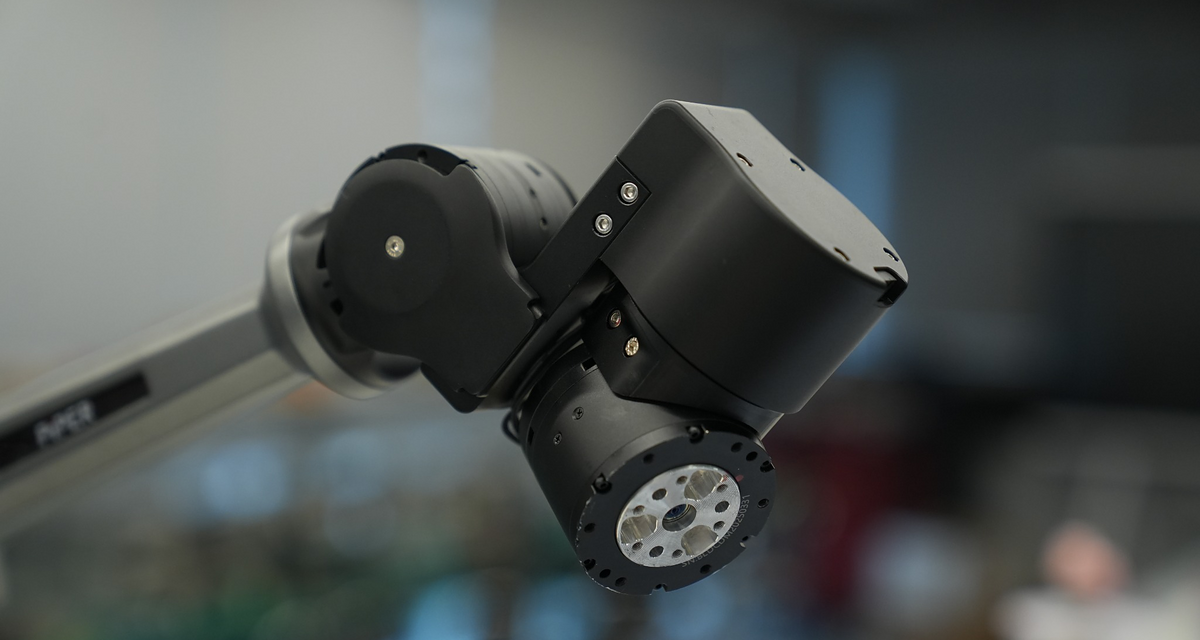
Precision Manipation in Confined Spaces
PiPER-X with the sphere wrist joint enables precise grasping, placement, insertion, and alignment in compact, cluttered, and hard-to-reach workspaces.
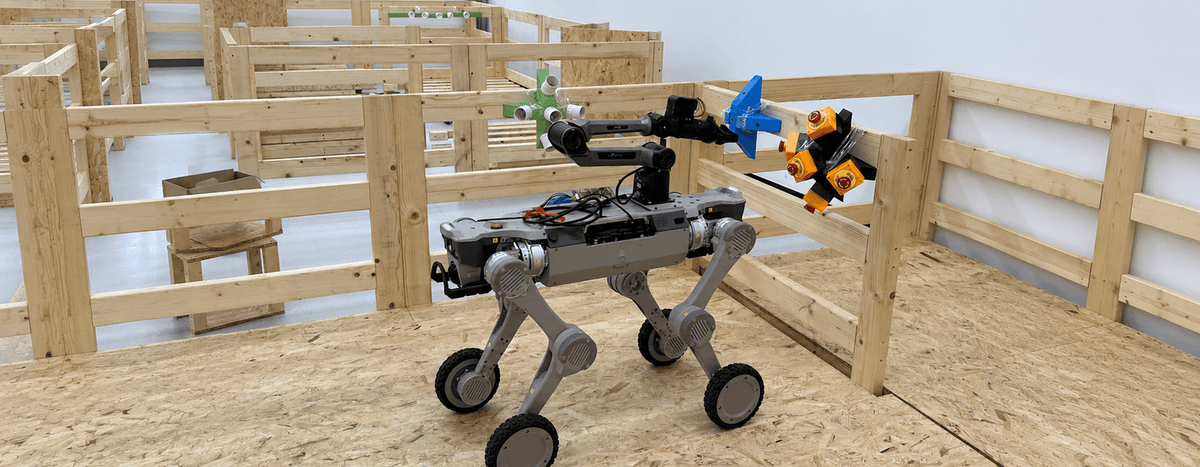
Robotics System Integration
PiPER-X integrates with quadruped robots to combine agile mobility with precise manipulation, enabling mobile inspection, object handling, and task execution in hard-to-reach environments.
Complete Ecosystem
Seamless integration with industry-standard hardware and software.
Components & Accessories
Equip PiPER-X with perception and end effectors for robotic manipulation, system integration, and physical AI research.

Dexterous Hand

Desktop Stand

Depth Camera & Vision System

Gripper & Teach Pendant
Software & Algorithms
Build and validate desktop robotic arm applications with integrated control tools, open SDKs, and simulation support.
ArmRobotTool PC Control
ROS 1 / ROS 2
Python SDK
URDF & Gazebo / Isaac Sim
PiPER Series Comparison
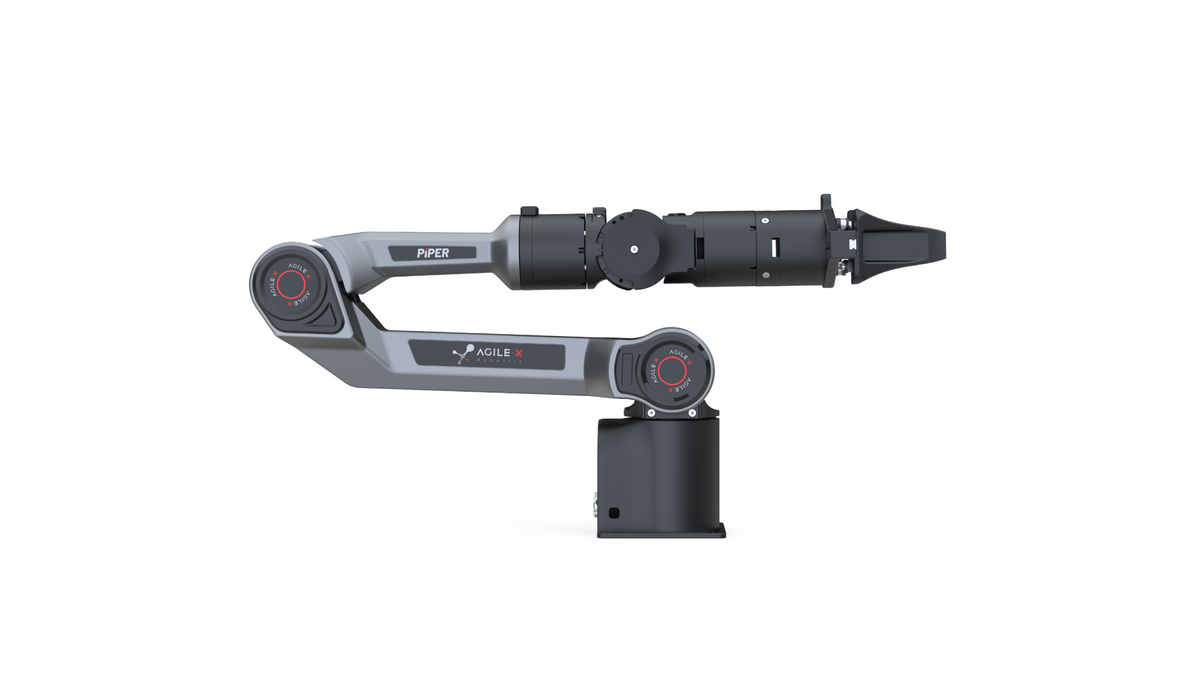
PiPER
General Purpose
1.5 kg
Payload
626 mm
Reach
4.2 kg
Weight
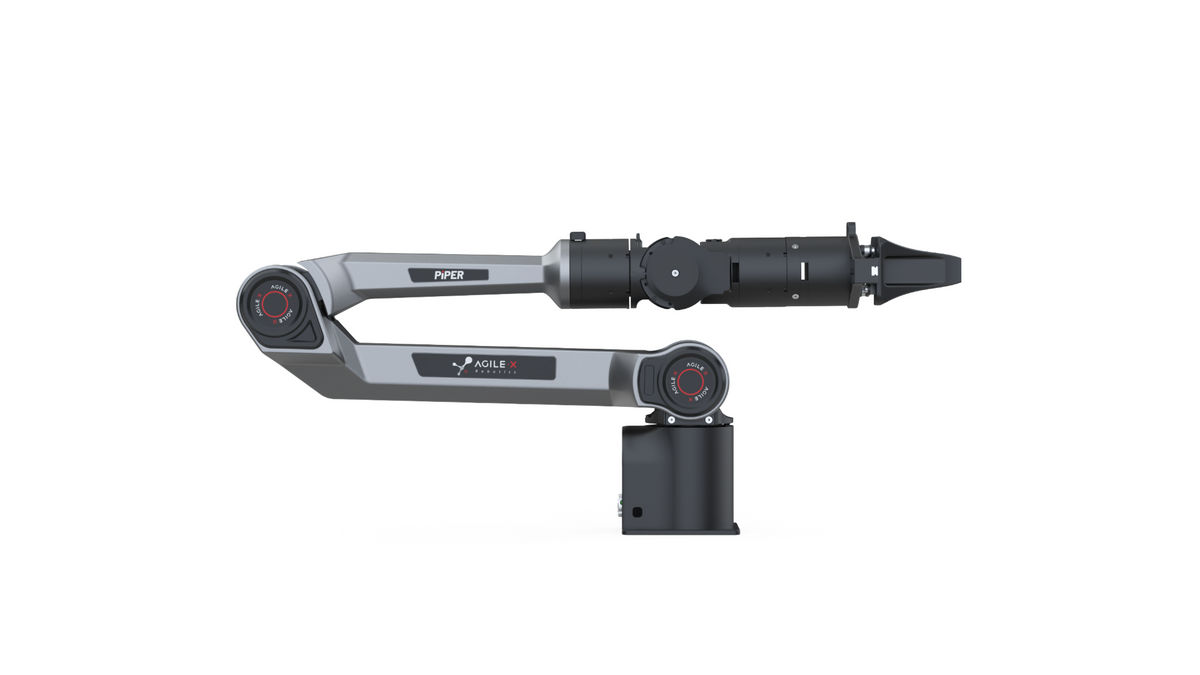
PiPER-L
Longer Reach
1.5 kg
Payload
750 mm
Reach
4.5 kg
Weight
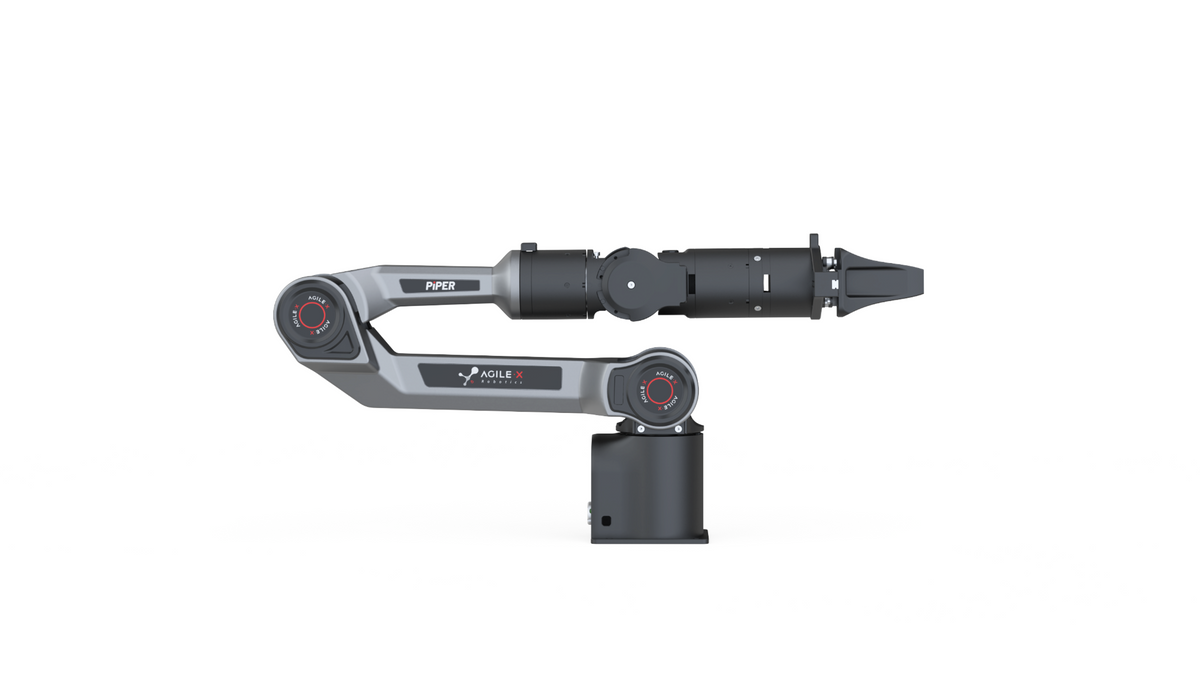
PiPER-H
Higher Payload
2 kg
Payload
669 mm
Reach
4.5 kg
Weight
FAQ
PiPER-X is a lightweight 6-DoF robot arm integrated with a highly flexible wrist designed for embodied AI, robotics research, imitation learning, motion planning, and precision manipulation in compact workspaces.
PiPER-X has a maximum payload of 1.5 kg, a 669 mm working radius. It weighs 4.5 kg, making it suitable for tabletop deployment and flexible laboratory setups.
PiPER-X provides ±0.1 mm repeatability for consistent and repeatable robotic motion.
Yes. Its 6-DoF structure, flexible wrist motion, open APIs, trajectory replay, and sensor-integration capabilities make it suitable for embodied AI, imitation learning, reinforcement learning, and robotic manipulation research.
Yes. PiPER-X is designed for tabletop mounting and compact research environments. It can also be integrated with other robotic systems.
Before operating PiPER, securely mount the arm, verify the power and CAN connections, calibrate the joint zero positions, and set the J6 zero point after installing an end-effector. Users should also confirm that the workspace is clear and complete a safety assessment. PiPER does not include automatic obstacle avoidance or sensing.
The included accessories depend on the selected configuration. Contact AgileX Robotics for available end-effectors, cameras, force sensors, and complete research kits.
PiPER-X is integrated with a sphere wrist, which enables more flexible wrist motion, and focuses on precise manipulation in compact research workspaces.
SPECIFICATIONS
Technical Specifications
DoF
6
Payload
1.5kg
Weight
4.5kg
Repeatability
±0.1mm
Reach
669mm
Voltage
DC 24V
Interface
CAN
Temperature
-20~50℃
Humidity
25~85%
Mounting Dimensions
70*70
J5 Joint Range
±90°
J5 Joint Speed
225°/s
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
marketing@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you within 24 hours.