
1.5m/s

RANGER AIR
Embodied AI Mobile Platform
Core Performance Metrics
80kg
Payload
2.5Hours
Runtime (Full Load)
8°
Climb
Provide Mobility for Embodied AI and Humanoid Robotics Systems
RANGER AIR is specifically designed to provide a compact mobile foundation for humanoid robots, bimanual systems, physical AI research, and mobile manipulation development.
Omnidirectional Mobility for Mobile Manipulation
Four-wheel steering enables zero-radius turning, lateral movement, and precise trajectory control, supporting alignment, repositioning, and manipulation in confined spaces.
Compact Mobile Robot Platform with 80 kg Payload
RANGER AIR combines a compact 552 × 500 mm footprint with an 80 kg rated moving payload, leaving sufficient capacity for robotic arms, sensors, and task-specific equipment.
Open Interfaces for Multi-Sensor Fusion
The platform supports integration with LiDAR, RGB-D cameras, IMUs, onboard computers, and ROS / ROS 2 development environments, enabling environment perception & obstacle avoidance.
Who Is RANGER AIR For?
Built for teams developing compact autonomous robots, mobile manipulation systems, and Physical AI applications across research and industry.
Humanoid & Physical AI Developers
Build mobile humanoid, bimanual, and embodied AI systems on a flexible omnidirectional base.
Mobile Manipulation Integrators
Integrate robotic arms, perception sensors, and onboard computing for autonomous mobile manipulation.
Warehouse & Manufacturing Operators
Develop agile transport and automation systems for aisles, production areas, and mixed indoor–outdoor routes.
Universities & Robotics Labs
Research autonomous navigation, motion control, sensor fusion, robot learning, and embodied intelligence.
RANGER AIR User Cases
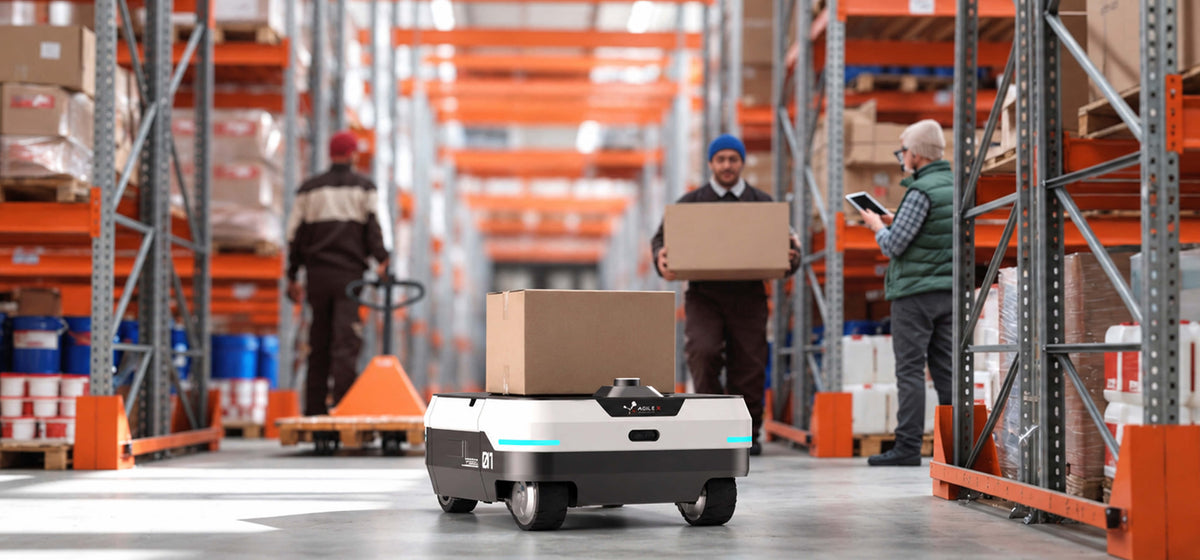
Warehousing Automation
Navigate narrow aisles and transport materials between storage, production, and workstation areas.
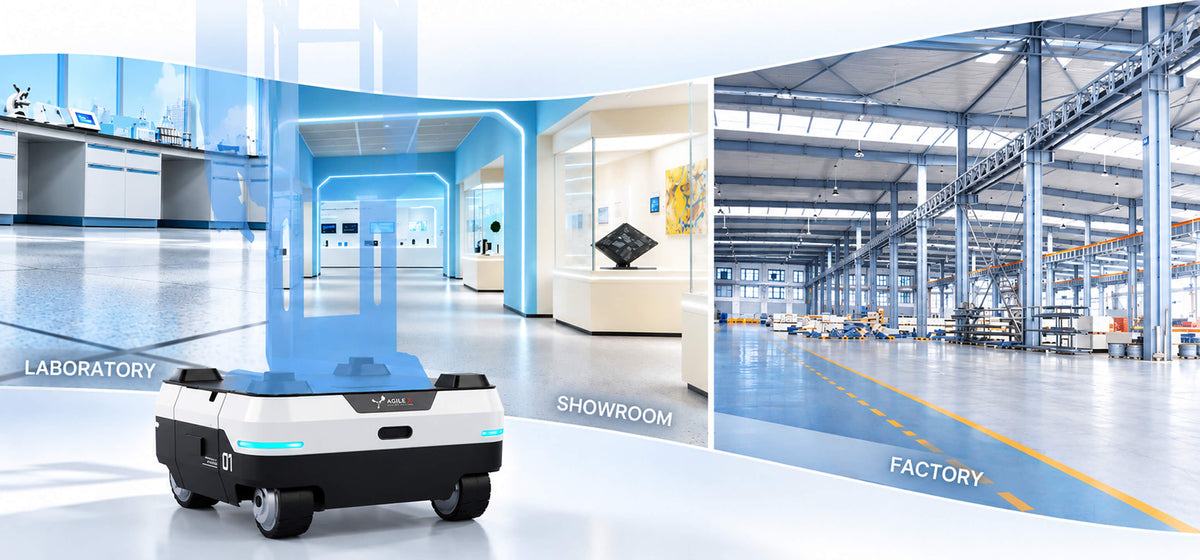
Humanoid Robotics & Physical AI Mobile Platform
Serve as a mobile base for humanoid upper bodies and bimanual systems, connecting perception, navigation, and manipulation for real-world Physical AI development.
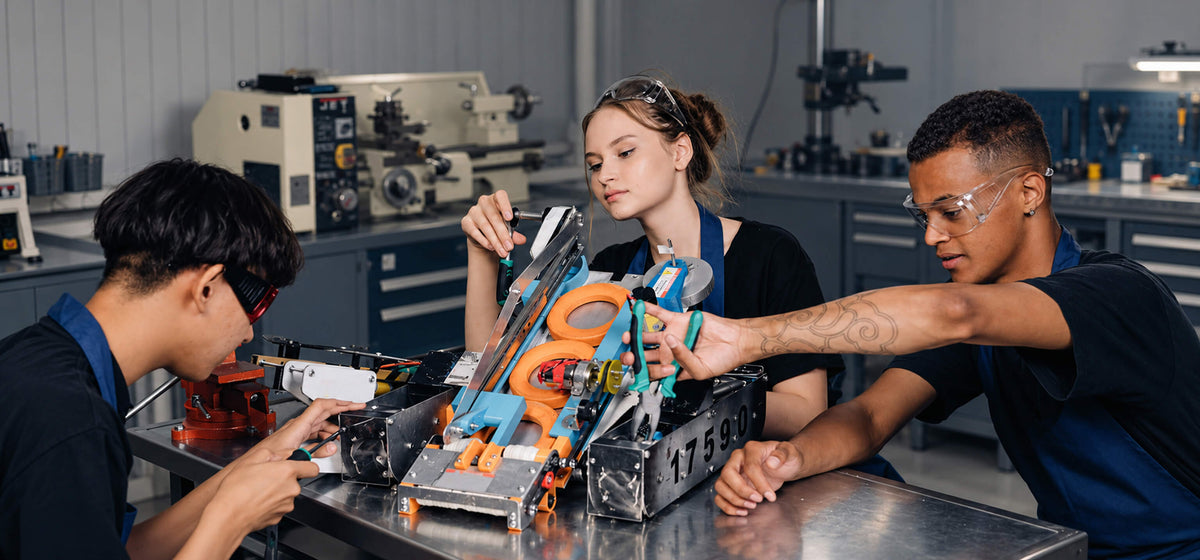
Robotics Research & Development
Support research in omnidirectional control, autonomous navigation, sensor integration, and mobile manipulation.
Complete Ecosystem
Seamless integration with industry-standard hardware and software
Components & Accessories
Integrate LiDAR, cameras, onboard computing, robotic arms, cargo modules, and application-specific payloads.

Robotic Arm

Depth Camera

LiDAR

Charging Dock
Software & Algorithms
Develop with CAN communication, SDK resources, ROS integration, simulation tools, SLAM, navigation, and robot control.
C++ SDK
CAN
ROS 1 & ROS 2 Packages
Navigation System
RANGER Series
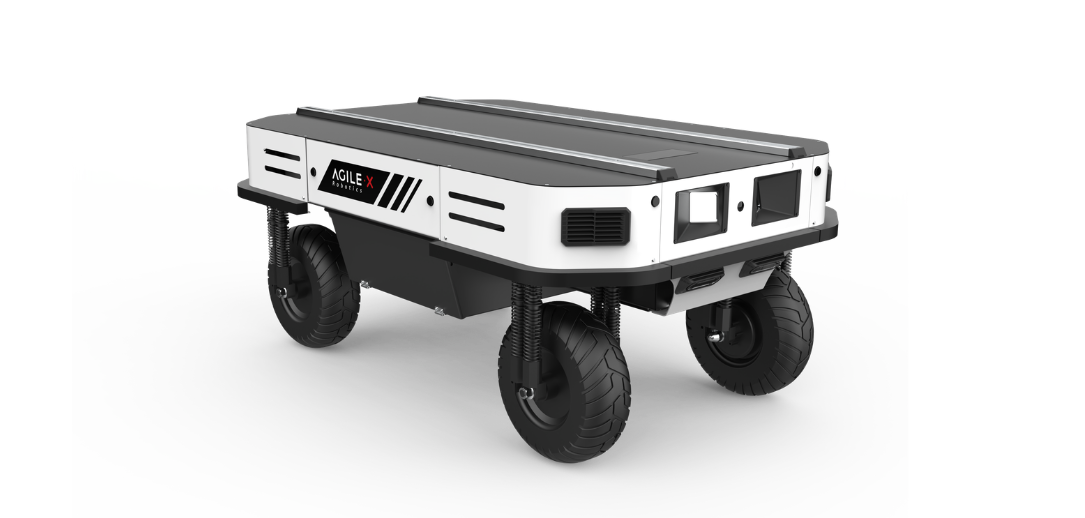
RANGER
Heavy-Duty Transport
Learn More
150 kg
Payload
2.6 m/s
Max Speed
IP55
IP Rating
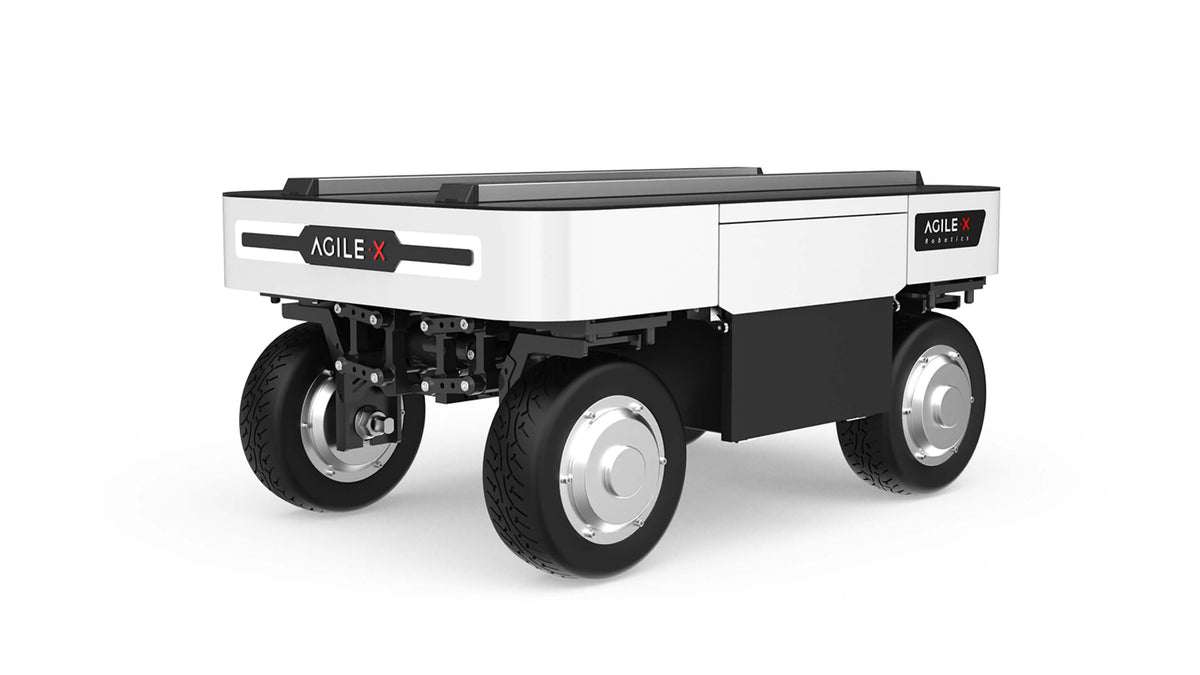
RANGER MINI 3.0
Compact Industrial Automation
Learn More
120 kg
Payload
2 m/s
Max Speed
IP54
IP Rating
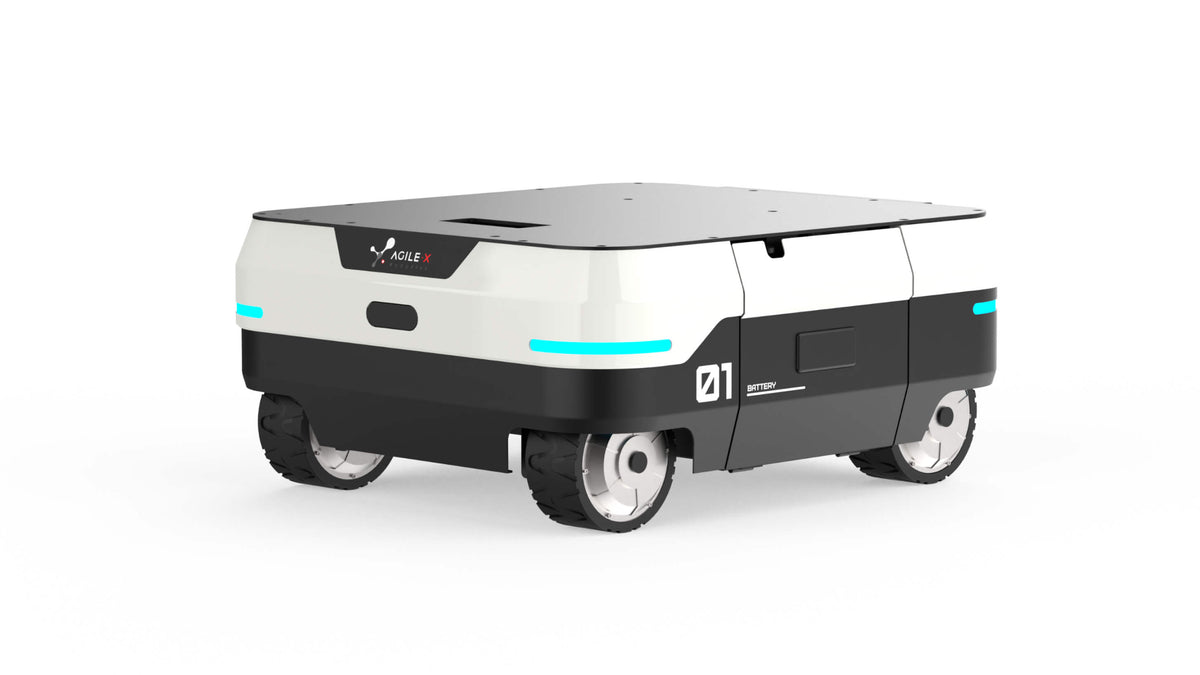
RANGER AIR
Physical AI & Mobile Manipulation
Learn More
80 kg
Payload
1.5 m/s
Max Speed
IP22
IP Rating
FAQ
RANGER AIR is a compact four-wheel-steering omnidirectional mobile platform for humanoid robots, embodied AI, mobile manipulation, and robotics research.
Its zero-radius turning, lateral movement, compact footprint, open interfaces, and 80 kg payload capacity support precise repositioning and integration with robotic arms and end-effectors.
RANGER AIR can be equipped with robotic arms, LiDAR, RGB-D cameras, IMUs, onboard computers, end-effectors, humanoid robot bodies, and other custom payloads.
Yes. RANGER AIR is compatible with ROS / ROS 2 development environments and supports CAN-based chassis control and motion feedback.
RANGER AIR is optimized for embodied AI, humanoid robots, bimanual systems, and mobile manipulation. RANGER MINI 3.0 provides higher payload and ground clearance for broader indoor/outdoor field robotics and delivery applications.
Technical Specifications
Motion Mode
4WD, 4WS
Weight
53±2kg
dimensions (mm)
552*500*250
IP Rating
IP22
Ground Clearance
45mm
Temperature
-10~40℃
Runtime (Full Load)
2.5hours
Climb
8°
Obstacle Clearance
10mm
Max Speed
1.5m/s
Max Range (Full Load)
25km
Payload
80kg
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you within 24 hours.