
Lightweight, Agile, and Ready to Go
Easy to carry and deploy across laboratories, workspaces, and real-world environments with calibration-free operations.

Easy to carry and deploy across laboratories, workspaces, and real-world environments with calibration-free operations.
Combine UMI-based manipulation capture with first-person egocentric sensing to record human hand movements, 6D poses, visual observations, gripper actions, and real-world interactions.
Align RGB, depth, pose, encoder, gripper, and trajectory data in real time to improve data consistency and usability, building high-quality, standardized datasets for robot learning.
An integrated system that streamlines data collection, management, and training workflows, supporting multi-device collaboration and task management.
Combine Pika Pro System with compatible robotic arms and end-effectors to support flexible teleoperation workflows, capturing real-world robot data across various environments.
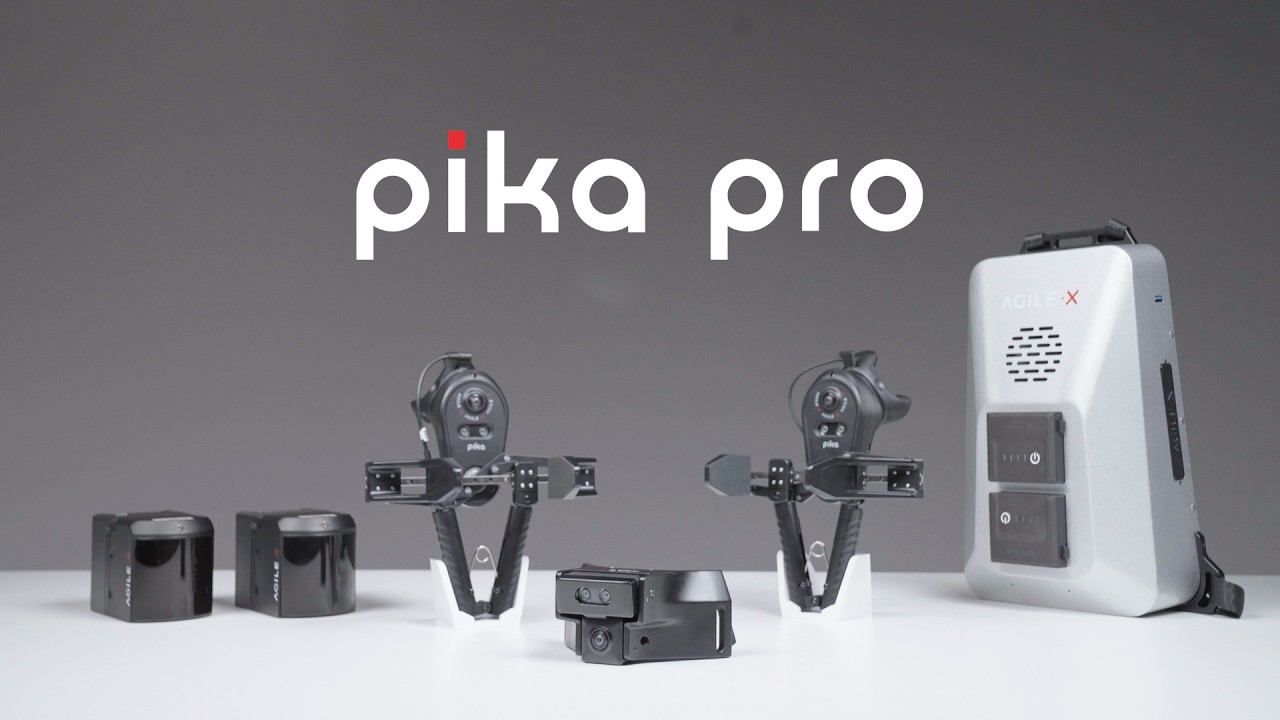
Record natural interactions using teleoperation, UMI gripper, and egocentric devices.
Align video, motion, and sensor data while enabling mobile, large-scale data collection.
Transform raw recordings into standardized, training-ready datasets.
Train foundation models for specific scenarios and deploy learned policies to robots.
Pika Pro enables scalable multimodal data collection across different applications.
Capture human demonstrations across household, laboratory, industrial, and desktop environments.


Collect synchronized RGB, 6D pose, gripper state, and trajectory data in one workflow.
Capture synchronized multimodal demonstrations with UMI gripper and EGO camera for scalable robot learning and embodied AI training.
For collecting multimodal data to train VLA models, world models, and robot policies.
For teaching and research in robot learning, teleoperation, computer vision, and manipulation.
For collecting task demonstrations and validating robotic manipulation solutions.
For building structured, scalable datasets from human-robot interaction and real-world demonstrations.

Build high-quality datasets for embodied AI, imitation learning, and robotic policy development.

Capture synchronized multimodal manipulation data across real-world industrial workflows.

Collect egocentric and manipulation data from diverse everyday household activities.

Deploy standardized UMI and EGO systems for consistent, large-scale data collection.
Pika Pro is a portable, multimodal data collection system engineered for precise, efficient data collection across environments, capturing egocentric data and information from UMI-based handheld grippers for robot learning, foundation model training, and physical AI research.
Pika Pro can collect RGB, depth, 6D pose, encoder or joint data, gripper state, and robot trajectory data, depending on the selected configuration.
Yes. Pika Pro provides ROS 1 and ROS 2 development support, including ROS drivers, URDF resources, and example programs.
Pika Sense provides up to ±1.5 mm spatial accuracy under unobstructed conditions, with pose data output at up to 120 Hz. Stable performance requires correct Pika Station placement.
Pika is designed to work with a range of robotic arms and end effectors. Official software support includes AgileX PiPER series arms, NERO, as well as selected third-party arms such as UFactory xArm Lite 6 and Universal Robots (UR). Compatibility may vary by control interface, software version, and application configuration; contact AgileX Robotics for the integration advice.
Yes. Pika Gripper can be used as an independent gripper or integrated with compatible third-party robotic arms through the appropriate mounting and communication interfaces. It can teleoperate external robotic arms or end effectors.
UMI (Universal Manipulation Interface) data collection captures human manipulation actions, hand poses, visual observations, and gripper states through a gripper. The synchronized data can be used for robot teleoperation, imitation learning, and manipulation policy training. Pika Sense & Pika Gripper form a portable UMI-style interface for capturing synchronized 6D motion, visual observations, and gripper actions.
Egocentric data collection records first-person visual and interaction experiences from the operator’s perspective. Pika Ego and Pika Package capture real-world human-environment interactions to support embodied AI and robot learning.
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.