
4.2kg

OPEN PiPER
6-DoF Bimanual Manipulation
Core Performance Metrics
1.5kg
Payload (Per Arm)
626mm
Reach (Per Arm)
±0.1mm
Repeatability
Lightweight Setup, Rapid Deployment
A modular structure and standardized components enable fast setup of a desktop dual-arm teleoperation prototype, shortening the development cycle from initial integration to application testing.
Bimanual Coordination with 6-DoF Robotic Arms
PiPER arms combine a 4.2 kg lightweight design, 1.5 kg payload, 626 mm reach, and ±0.1 mm repeatability for desktop robot manipulation research and prototyping.
Open and Expandable for Secondary Development
Complete development interfaces and example programs support rapid teleoperation and data collection setup, reducing integration effort and enabling iterative development across embodied AI tasks.
Who is Using OPEN PiPER
A lightweight and accessible robotic platform for hands-on Physical AI research, education, bimanual manipulation, and rapid experimentation.
Robotics & Embodied AI Research Labs
A compact platform for robot learning, imitation learning, manipulation, and embodied AI research.
Robotics & AI Educators
Enable hands-on teaching of teleoperation, perception, motion control, and bimanual coordination.
Embodied AI Developers
Rapidly validate manipulation algorithms and learning policies with a lightweight real-world setup.
Startups & Independent Developers
Build affordable prototypes and customized manipulation systems without heavy laboratory infrastructure.
OPEN PiPER User Cases
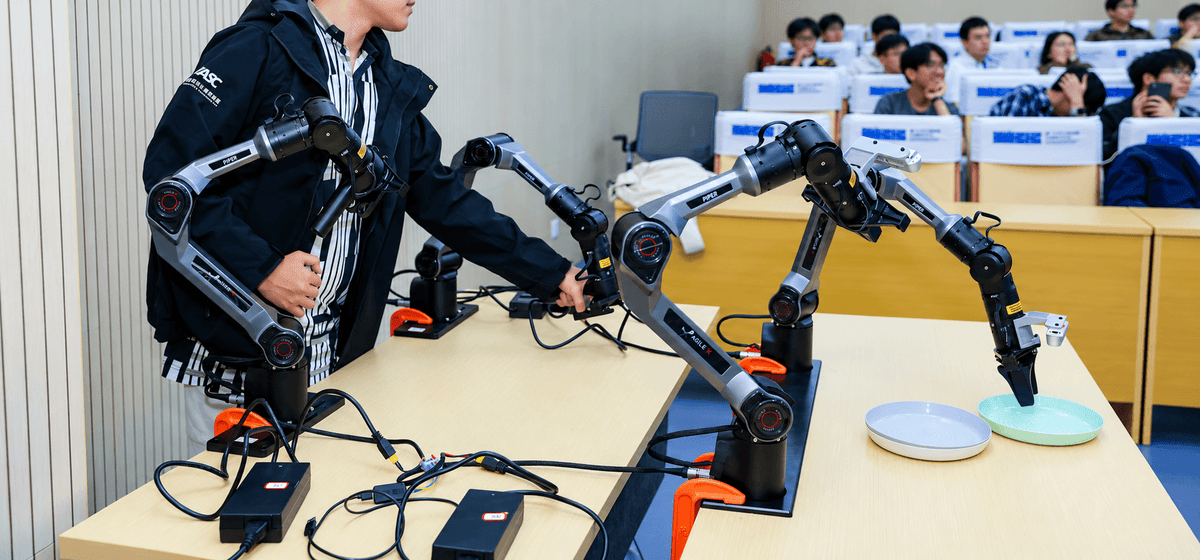
Lightweight Robot Data Collection Setup
Create a compact, portable setup for efficiently collecting real-world manipulation demonstrations.
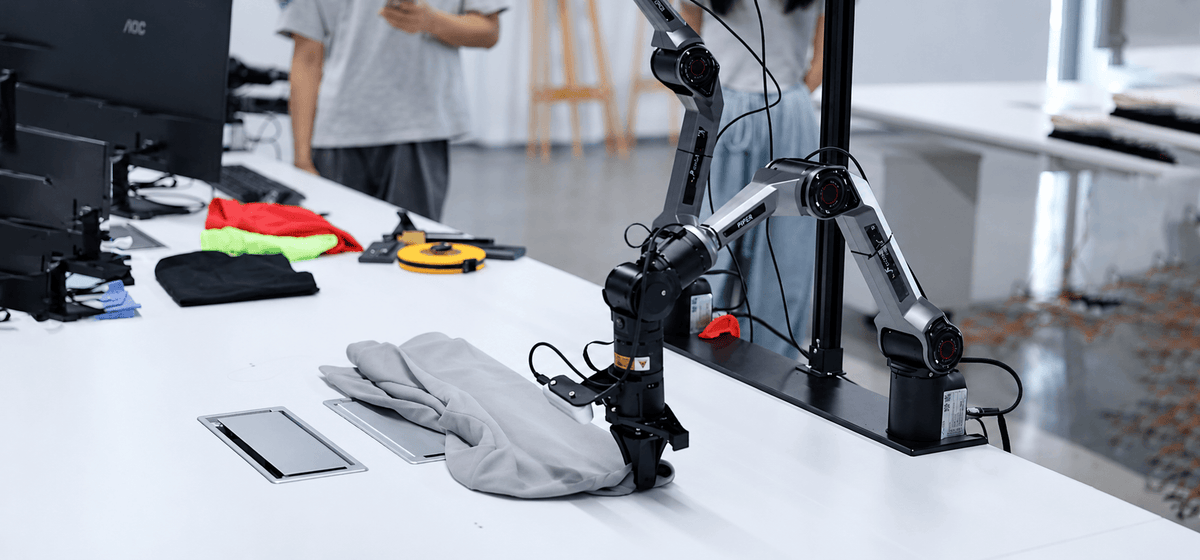
Physical AI Research & Education
Support hands-on experiments in robot learning, teleoperation, imitation learning, and manipulation.
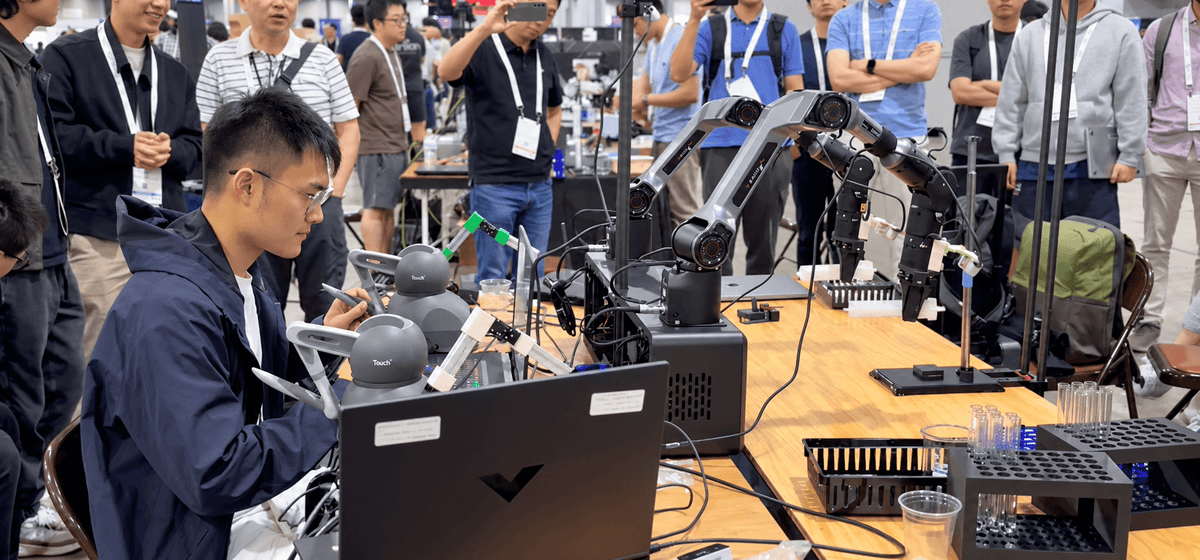
Bimanual Manipulation & Interactive Demonstration
Enable coordinated dual-arm tasks and intuitive demonstrations for manipulation-policy development.
Related Solutions
Extend OPEN NERO into complete robotic systems for teleoperation, real-world data collection, and embodied AI development.

Universal Master Arm
Universal Master Arm is a lightweight 6-DoF teleoperation leader arm designed for robotic arm control and human demonstration. It enables real-time teleoperation through 6D pose mapping and IK-based motion.
Learn More
OPEN NERO
OPEN NERO is a desktop dual-arm platform powered by two NERO 7-DoF robotic arms that enables bimanual teleoperation and multimodal data collection for robot learning and embodied AI research.
Learn MoreFAQ
OPEN PiPER is a lightweight 6-DoF dual-arm teleoperation platform for bimanual manipulation, robot data collection, and embodied AI prototyping.
OPEN PiPER focuses on lightweight deployment, standardized components, rapid assembly, and accessible system development. OPEN NERO provides 7-DoF redundant arms, richer multimodal data support, and a more advanced ROS 2 and LeRobot research environment.
Yes. Developers can add sensors, grippers, and other actuator modules according to different research and manipulation tasks.
OPEN PiPER is designed for universities, research labs, educators, developers, and makers who need a compact and easy-to-deploy platform for bimanual manipulation research.
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan, Guangdong, China
Sales & Marketing: iPark, Nanshan District, Shenzhen, Guangdong, China
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.