
For four consecutive years, AgileX Robotics has joined ROSCon, the global developer conference for the ROS and open-source robotics community.
From ROSCon 2023 in New Orleans and ROSCon 2024 in Odense to ROSCon 2025 in Singapore and 2026 in Toronto, our journey with ROSCon has followed the evolution of our robotics platforms — from ROS mobile robots and navigation platforms to robotic arms, teleoperation, robot data collection, and embodied AI infrastructure.
Each year, we have brought new hardware to ROSCon for developers, researchers, and robotics engineers working with ROS 2, control, manipulation, simulation, and robot learning.

AgileX Robotics: 4 Years of Building with the ROS Community
ROSCon is more than a robotics exhibition. It is where the global ROS 2 developer community comes together to exchange technical ideas, open-source tools, and real-world experience across robotics ecosystem.
For AgileX Robotics, ROSCon has become an important point to connect reliable physical robotics platforms with the broader ROS ecosystem.
Over the past four years, our ROSCon lineup has included robotics platforms across ROS education, manipulation, industry AMR solutions, and embodied AI including robot data collection.
The platforms have changed, but the goal has remained consistent: helping developers move more easily from ROS development, simulation, and algorithms to real-world robot deployment.
ROSCon 2023-2024: From ROS Mobile Robots to Robot Manipulation
Our earlier participation at ROSCon focused heavily on ROS mobile robotics.
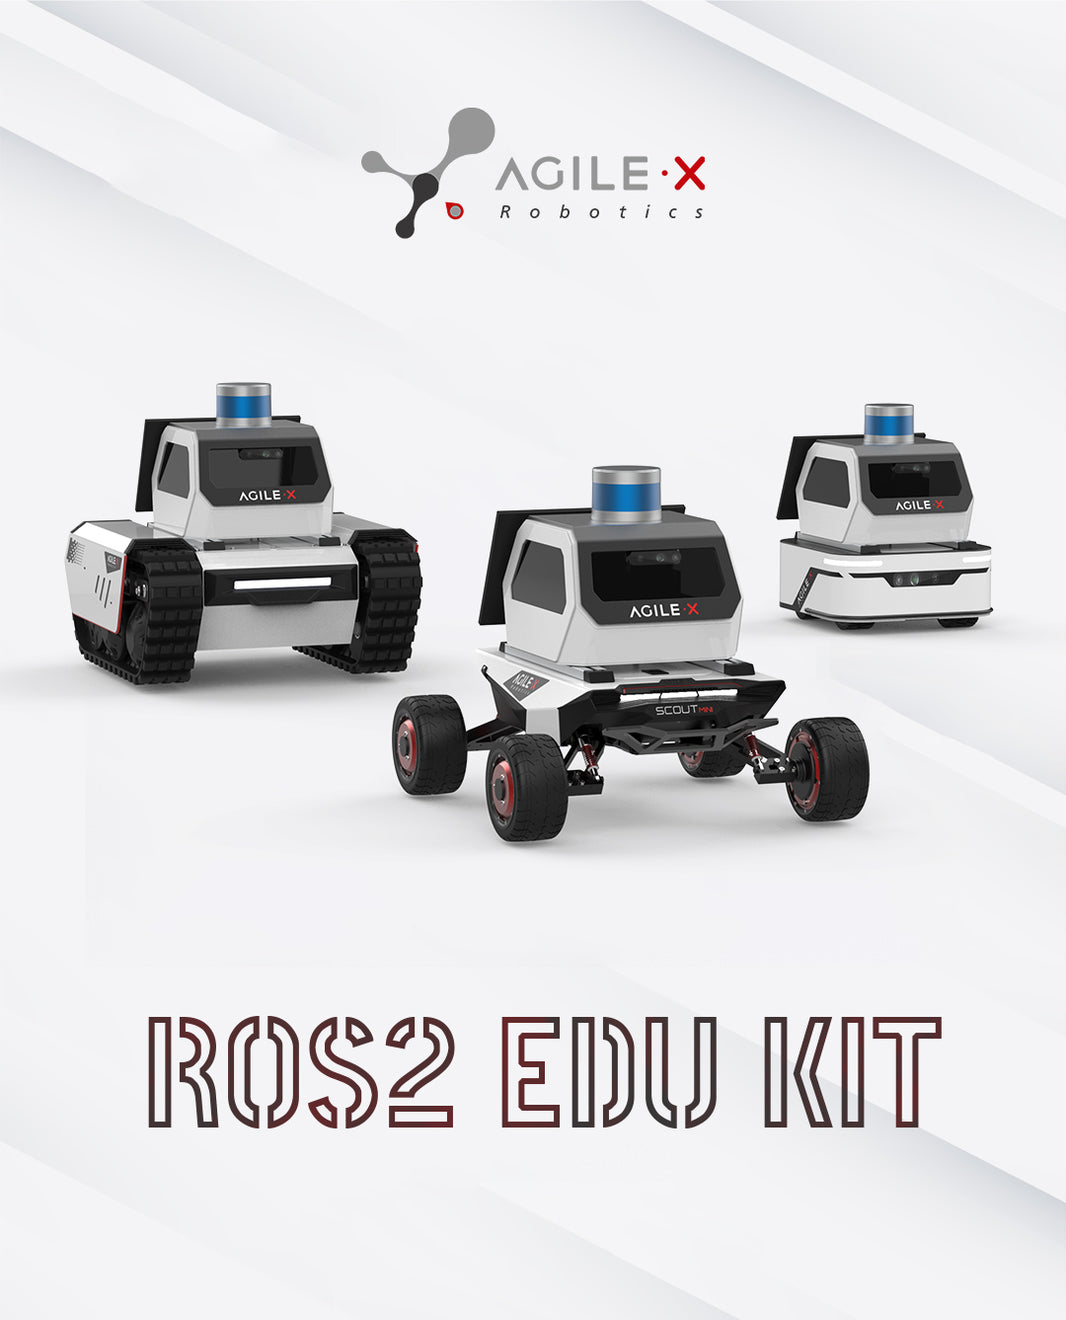
Platforms such as LIMO ROS education platform and UMR provided physical hardware for developers exploring ROS navigation, SLAM, autonomous mobility, sensor integration, mapping, and robotics education.
As the AgileX robotics ecosystem expanded, our focus also moved beyond mobility.
With PiPER and PiPER-X robotic arms, we brought robot manipulation into our ROS platform portfolio, supporting applications including motion planning, manipulation research, system integration, and ROS 2 development.
This reflected a broader shift in robotics: from enabling robots to navigate the physical world to enabling them to actively interact with it.

ROSCon 2024 in Odense
ROSCon 2025-2026: From Robot Control to Embodied AI Data Solution
More recently, robotics research has increasingly moved toward robot learning and physical AI research.
In these workflows, ROS-compatible hardware is only one layer of the system. Developers also need ways to collect human demonstrations, synchronize multimodal data, and connect real-world interaction with robot learning pipelines.
The Pika data collection gripper represented another step in this direction, supporting intuitive real-world demonstration and data collection for robot learning and embodied AI research.
Our platform roadmap was therefore evolving beyond individual ROS robots toward a broader development infrastructure connecting:
Robot Hardware → Control → Teleoperation → Data Collection → Robot Learning

ROSCon 2025 in Singapore
ROSCon Global 2026: Broader Teleoperation Meets ROS 2
At ROSCon Global 2026 in Toronto, AgileX Robotics is continuing this evolution with the Universal Master Arm, our latest teleoperation platform for robotic arm control and human demonstration.
Designed to work with different robotic arms including PiPER and NERO, the Universal Master Arm translates human movement into continuous robot motion through 6D pose mapping and inverse-kinematics-based control.
For ROS and ROS 2 developers, this creates a practical workflow for:
-
robotic arm teleoperation and control
-
manipulation research
-
human demonstration collection
-
robot learning dataset generation
-
embodied AI development
-
real-world robotics experimentation
 Universal Master Arm Teleoperation Platform
Four ROSCons, One Evolving Robotics Stack
For AgileX Robotics, supporting ROS goes beyond providing a ROS driver or ROS 2 interface. It means building robotics platforms that developers can integrate into real-world research and development workflows, from robot control and teleoperation to learning and embodied AI.
AgileX Robotics will be at ROSCon Global 2026 in Sheraton Centre Toronto, Canada, from September 22–24, 2026.
At Booth 48, visitors can experience hands-on teleoperation with the Universal Master Arm, PiPER 6-DoF robotic arm, and NERO 7-DoF humanoid arm, and explore how ROS 2 connects robot hardware, human demonstrations, manipulation, and embodied AI development.
See you at ROSCon Global 2026 — Booth 48 in Toronto.

Teleoperation with Universal Master Arm
FAQ
How does AgileX Robotics support ROS and ROS 2 development?
AgileX Robotics supports ROS and ROS 2 development through robotics hardware, software interfaces, SDKs, simulation resources, and platforms designed for real-world testing, control, teleoperation, and robot learning.
Are robots from AgileX Robotics compatible with ROS 2?
AgileX Robotics' robot arms such as PiPER and NERO support ROS-based development and can be integrated into workflows involving robot control, manipulation, teleoperation, and research applications.
What is AgileX Robotics showcasing at ROSCon Global 2026?
At ROSCon Global 2026, AgileX Robotics is showcasing PiPER 6-DoF robot arm, NERO 7-DoF robot arm, and the Universal Master Arm, with a focus on robotic arm teleoperation, ROS 2 development, and real-world manipulation.
How is teleoperation used in ROS robotics development?
Teleoperation allows developers to control robots directly, collect human demonstrations, test manipulation tasks, and generate real-world interaction data that can support robot learning and embodied AI research.
Why is ROSCon important for robotics developers?
ROSCon Global 2026 brings together developers, researchers, and companies working across the ROS ecosystem, making it an important venue for sharing open-source tools, technical workflows, and real-world robotics applications.