
4.8kg

OPEN NERO
7-DoF Bimanual Teleoperation
Core Performance Metrics
3kg
Payload (Per Arm)
580mm
Reach (Per Arm)
±0.1mm
Repeatability

Smooth Setup & Flexible Deployment
OPEN NERO features a compact desktop design, making it efficient for quick setup and flexible deployment across different environments and manipulation tasks.

Multimodal Robot Data Collection
OPEN NERO synchronizes RGB, depth, joint angles, end-effector poses, and gripper width data for imitation learning, VLA training, and robot policy development.

Easy-to-use Web Interface for Task Management
Users can manage data collection tasks through a unified web interface with intuitive controls, making teleoperation workflows easier to deploy, repeat, and scale.
Who is Using OPEN NERO
Serve the scalable needs of robotics research, education, algorithm development, and agile real-world robot prototyping.
Robotics & Embodied AI Research Labs
For universities and research institutes studying bimanual manipulation, teleoperation, imitation learning, and robot control.
Humanoid Robot Developers
For teams developing humanoid and dual-arm robots, enabling teleoperation, manipulation validation, and coordination development.
Robot Learning & Data Teams
For collecting synchronized real-world demonstrations to train and evaluate imitation learning and manipulation policies.
Industrial Robotics R&D
For prototyping dual-arm manipulation tasks such as assembly, handling, sorting, and other coordinated operations.
OPEN NERO User Cases
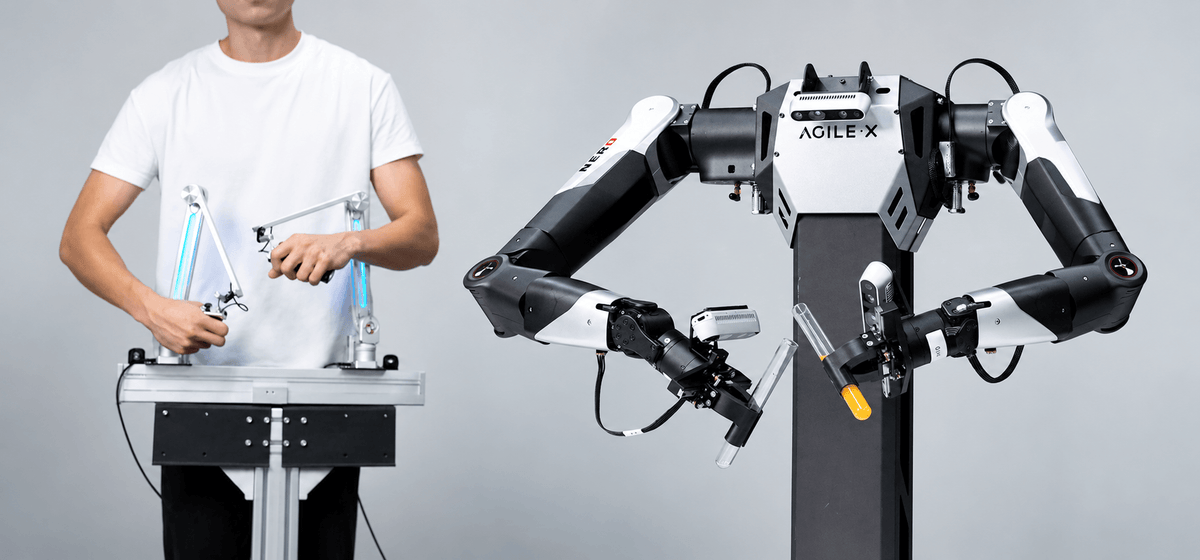
Real-World Robot Data Collection
Capture dual-arm demonstrations through intuitive teleoperation. Build high-quality real-world datasets for imitation learning and robot policy training.
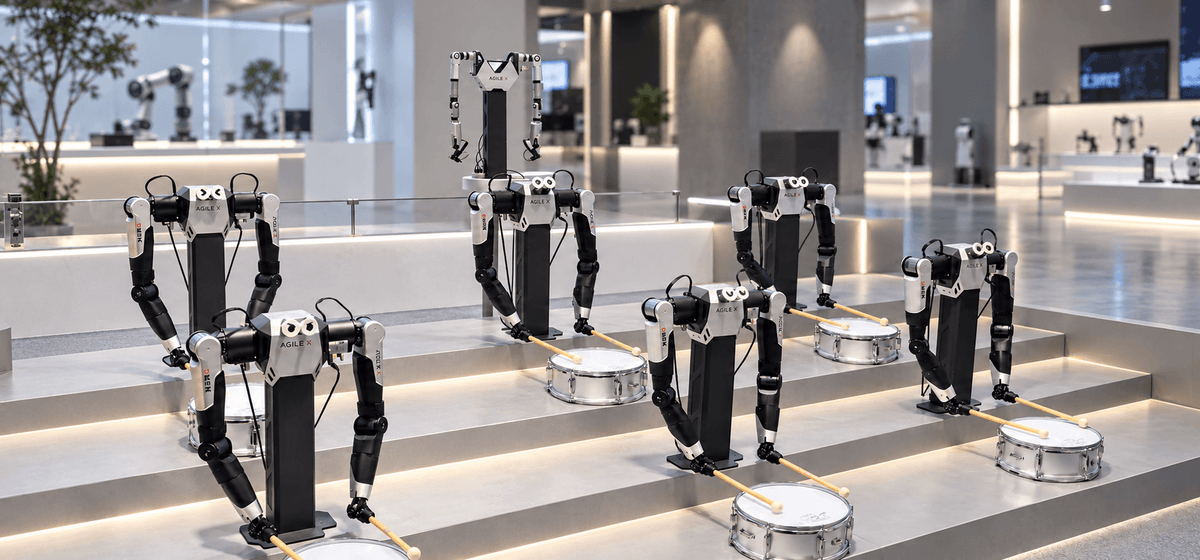
Complex Bimanual Manipulation & Coordination Research
Develop and validate coordinated dual-arm robot control for complex manipulation tasks. Explore motion planning and bimanual collaboration.
Complete Ecosystem
Components & Accessories
OPEN NERO is pre-integrated with vision sensors and computing units for diverse applications.

NERO 7-DoF Humanoid Arm

Universal Master Arm

Dual-Arm Stand

Depth Camera
Software & Algorithms
Develop and validate teleoperation data and robot learning workflows.
LeRobot
MCAP
ROS 2 Humble
Ubuntu 22.04 LTS
Related Solutions
Extend OPEN NERO into complete robotic systems for teleoperation, real-world data collection, and embodied AI development.

Universal Master Arm
Universal Master Arm is a lightweight 6-DoF teleoperation leader arm designed for robotic arm control and human demonstration. It enables real-time teleoperation through 6D pose mapping and IK-based motion.
Learn More
OPEN PiPER
A 6-DoF lightweight bimanual manipulation platform built with two PiPER robotic arms. It provides an accessible and efficient foundation for bimanual coordination research and teleoperation data collection.
Learn MoreFAQ
OPEN NERO is a desktop dual-arm platform powered by two NERO 7-DoF robotic arms that enables bimanual teleoperation and multimodal data collection for robot learning and embodied AI research.
OPEN NERO uses 7-DoF arms with redundant motion, making it better suited to dexterous manipulation, complex posture adjustment, and advanced robot learning research. OPEN PiPER focuses on lightweight deployment, rapid assembly, and accessible dual-arm development.
OPEN NERO can collect synchronized RGB, depth, joint angle, end-effector pose, and gripper width data for robot learning and policy training.
Technical Specifications
DoF (Per Arm)
7
Payload (Per Arm)
3kg
Weight (Per Arm)
4.8kg
Repeatability (Per Arm)
±0.1mm
Reach (Per Arm)
580mm
Gripper Width
0-100mm
Data Formats
MCAP; LeRobot
Onboard PC
Intel i5-12450H
Tell Us Your Needs
Connect with our robotics experts to discuss your needs and discover the perfect robotics platform for your business.
AFTER-SALES
support@agilex.aiADDRESS
Head Office: XbotPark, Songshan Lake, Dongguan
Sales & Marketing: iPark, Nanshan District, Shenzhen
Thank You!
Your inquiry has been received. Our robotics engineers will get back to you as soon as possible.